PR2CopyStateTest Class Reference
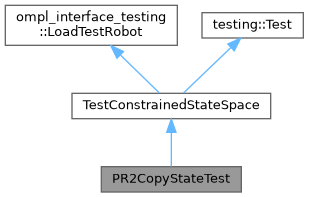
Inheritance diagram for PR2CopyStateTest:
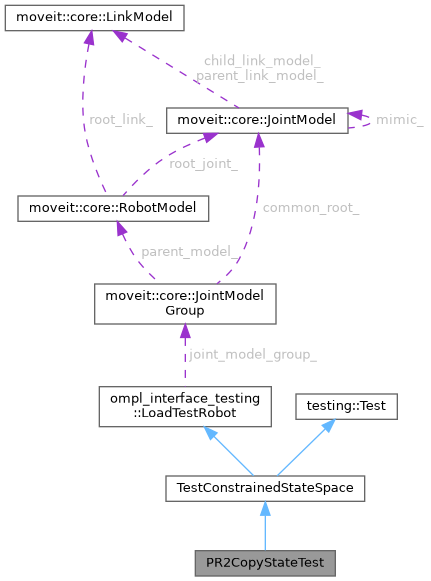
Collaboration diagram for PR2CopyStateTest:
Protected Member Functions | |
| PR2CopyStateTest () | |
| Protected Member Functions inherited from TestConstrainedStateSpace | |
| TestConstrainedStateSpace (const std::string &robot_name, const std::string &group_name) | |
| void | SetUp () override |
| void | TearDown () override |
| void | setupMoveItStateSpace () |
| void | setupOMPLStateSpace () |
| void | testGetValueAddressAtIndex () |
| void | testCopyToRobotState () |
| void | testCopyToOMPLState () |
| void | testCopyJointToOMPLState () |
| Protected Member Functions inherited from ompl_interface_testing::LoadTestRobot | |
| LoadTestRobot (const std::string &robot_name, const std::string &group_name) | |
| Eigen::VectorXd | getRandomState () const |
| Eigen::VectorXd | getDeterministicState () const |
| Create a joint position vector with values 0.1, 0.2, 0.3, ... where the length depends on the number of joints in the robot. | |
Additional Inherited Members | |
| Protected Attributes inherited from TestConstrainedStateSpace | |
| ompl::base::ConstrainedStateSpacePtr | constrained_state_space_ |
| ompl_interface::ConstrainedPlanningStateSpacePtr | moveit_state_space_ |
| Protected Attributes inherited from ompl_interface_testing::LoadTestRobot | |
| std::string | group_name_ |
| std::string | robot_name_ |
| moveit::core::RobotModelPtr | robot_model_ |
| moveit::core::RobotStatePtr | robot_state_ |
| const moveit::core::JointModelGroup * | joint_model_group_ |
| std::size_t | num_dofs_ |
| std::string | base_link_name_ |
| std::string | ee_link_name_ |
Detailed Description
Definition at line 309 of file test_constrained_planning_state_space.cpp.
Constructor & Destructor Documentation
◆ PR2CopyStateTest()
|
inlineprotected |
Definition at line 312 of file test_constrained_planning_state_space.cpp.
Here is the call graph for this function:

The documentation for this class was generated from the following file:
- moveit_planners/ompl/ompl_interface/test/test_constrained_planning_state_space.cpp
Generated by
 1.15.0