moveit_cpp.cpp File Reference
#include "moveit_cpp.hpp"#include <pybind11/pytypes.h>#include <moveit/utils/logger.hpp>#include <string>
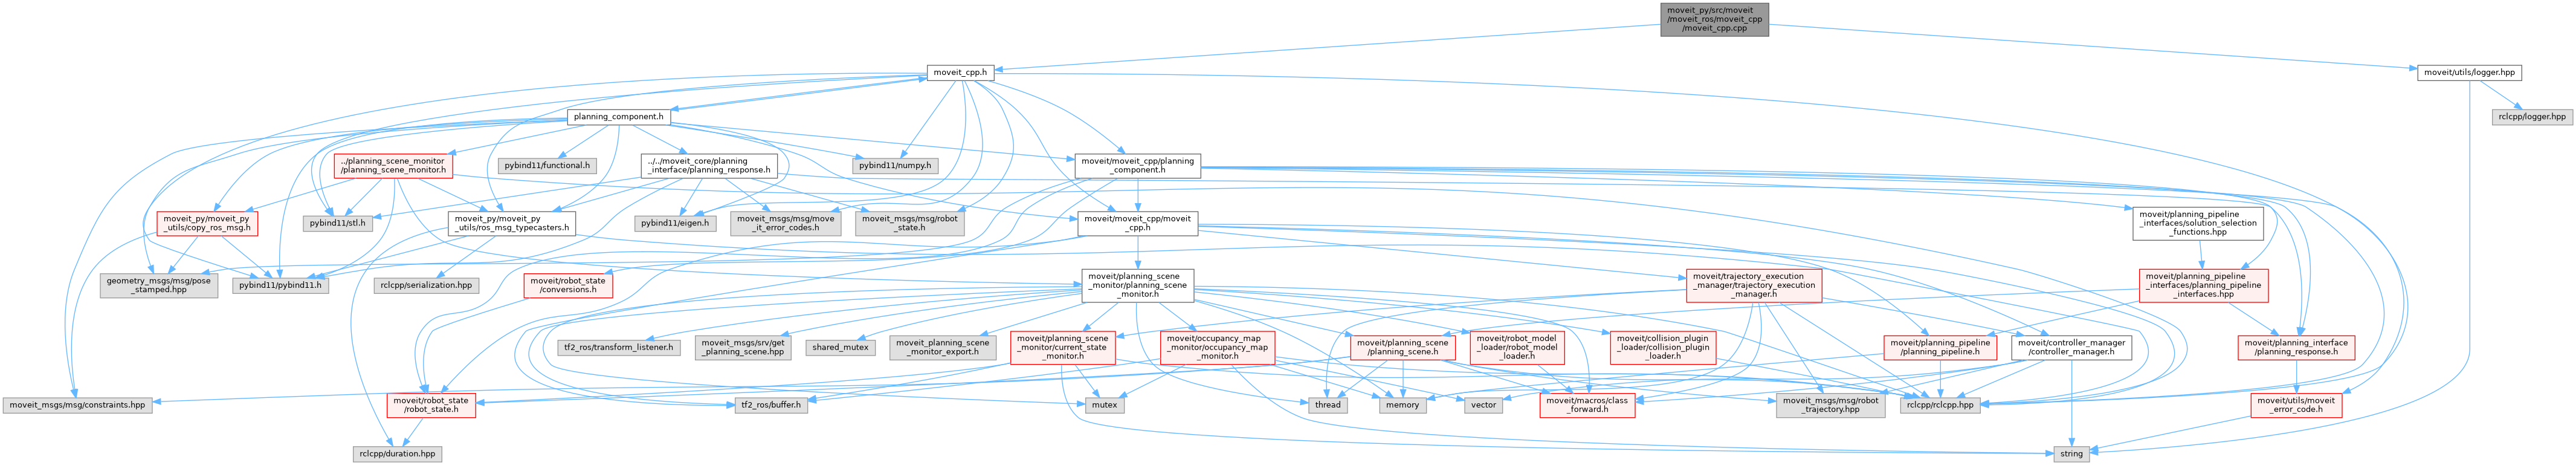
Include dependency graph for moveit_cpp.cpp:
Go to the source code of this file.
Namespaces | |
| namespace | moveit_py |
| namespace | moveit_py::bind_moveit_cpp |
Functions | |
| rclcpp::Logger | moveit_py::bind_moveit_cpp::getLogger () |
| std::shared_ptr< moveit_cpp::PlanningComponent > | moveit_py::bind_moveit_cpp::getPlanningComponent (std::shared_ptr< moveit_cpp::MoveItCpp > &moveit_cpp_ptr, const std::string &planning_component) |
| void | moveit_py::bind_moveit_cpp::initMoveitPy (py::module &m) |
Generated by
 1.15.0