ompl_interface::BoxConstraint Class Reference
Box shaped position constraints. More...
#include <ompl_constraints.hpp>
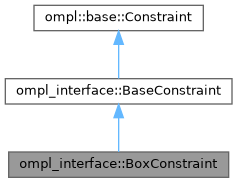
Inheritance diagram for ompl_interface::BoxConstraint:
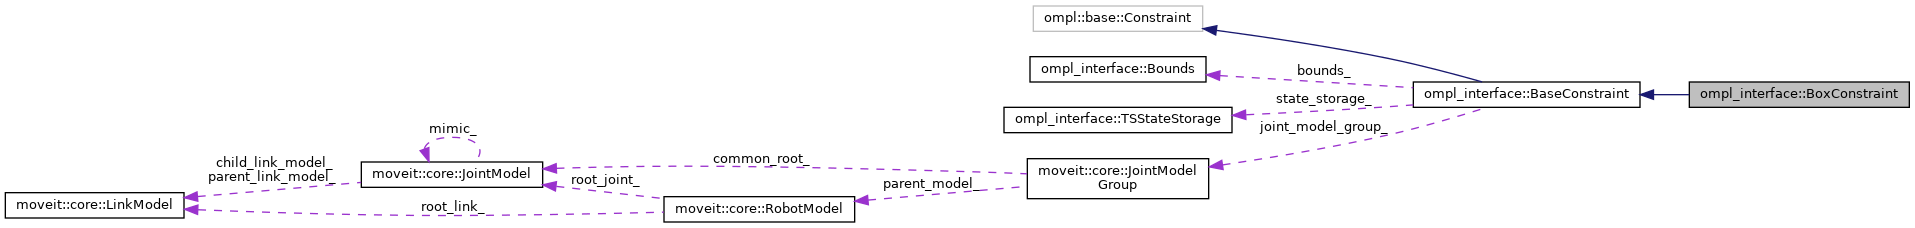
Collaboration diagram for ompl_interface::BoxConstraint:
Public Member Functions | |
| BoxConstraint (const moveit::core::RobotModelConstPtr &robot_model, const std::string &group, const unsigned int num_dofs) | |
| void | parseConstraintMsg (const moveit_msgs::msg::Constraints &constraints) override |
| Parse bounds on position parameters from MoveIt's constraint message. | |
| Public Member Functions inherited from ompl_interface::BaseConstraint | |
| BaseConstraint (const moveit::core::RobotModelConstPtr &robot_model, const std::string &group, const unsigned int num_dofs, const unsigned int num_cons=3) | |
| Construct a BaseConstraint using 3 num_cons by default because all constraints currently implemented have 3 constraint equations. | |
| void | init (const moveit_msgs::msg::Constraints &constraints) |
| Initialize constraint based on message content. | |
| void | function (const Eigen::Ref< const Eigen::VectorXd > &joint_values, Eigen::Ref< Eigen::VectorXd > out) const override |
| void | jacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_values, Eigen::Ref< Eigen::MatrixXd > out) const override |
| Jacobian of the constraint function. | |
| Eigen::Isometry3d | forwardKinematics (const Eigen::Ref< const Eigen::VectorXd > &joint_values) const |
| Wrapper for forward kinematics calculated by MoveIt's Robot State. | |
| Eigen::MatrixXd | robotGeometricJacobian (const Eigen::Ref< const Eigen::VectorXd > &joint_values) const |
| Calculate the robot's geometric Jacobian using MoveIt's Robot State. | |
| const std::string & | getLinkName () |
| const Eigen::Vector3d | getTargetPosition () |
| const Eigen::Quaterniond | getTargetOrientation () |
Additional Inherited Members | |
| Public Attributes inherited from ompl_interface::BaseConstraint | |
| const | |
| For inequality constraints: calculate the value of the parameter that is being constrained by the bounds. | |
| Protected Attributes inherited from ompl_interface::BaseConstraint | |
| TSStateStorage | state_storage_ |
| Thread-safe storage of the robot state. | |
| const moveit::core::JointModelGroup * | joint_model_group_ |
| std::string | link_name_ |
| Robot link the constraints are applied to. | |
| Bounds | bounds_ |
| Upper and lower bounds on constrained variables. | |
| Eigen::Vector3d | target_position_ |
| target for equality constraints, nominal value for inequality constraints. | |
| Eigen::Quaterniond | target_orientation_ |
| target for equality constraints, nominal value for inequality constraints. | |
Detailed Description
Box shaped position constraints.
Reads bounds on x, y and z position from a position constraint at constraint_region.primitives[0].dimensions. Where the primitive has to be of type shape_msgs/SolidPrimitive.BOX.
These bounds are applied around the nominal position and orientation of the box.
Definition at line 257 of file ompl_constraints.hpp.
Constructor & Destructor Documentation
◆ BoxConstraint()
Member Function Documentation
◆ parseConstraintMsg()
|
overridevirtual |
Parse bounds on position parameters from MoveIt's constraint message.
This can be non-trivial given the often complex structure of these messages.
Implements ompl_interface::BaseConstraint.
Definition at line 204 of file ompl_constraints.cpp.
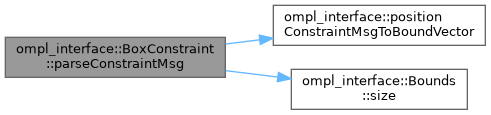
Here is the call graph for this function:
The documentation for this class was generated from the following files:
- moveit_planners/ompl/ompl_interface/include/moveit/ompl_interface/detail/ompl_constraints.hpp
- moveit_planners/ompl/ompl_interface/src/detail/ompl_constraints.cpp
Generated by
 1.15.0