test.unit.test_planning_scene.TestPlanningSceneGilRelease Class Reference
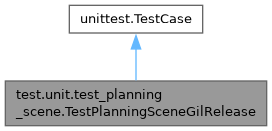
Inheritance diagram for test.unit.test_planning_scene.TestPlanningSceneGilRelease:
Collaboration diagram for test.unit.test_planning_scene.TestPlanningSceneGilRelease:
Public Member Functions | |
| setUpClass (cls) | |
| setUp (self) | |
| assert_releases_gil (self, call) | |
| test_is_state_valid (self) | |
| test_is_state_colliding_current_state (self) | |
| test_is_state_colliding (self) | |
| test_check_collision (self) | |
| test_check_collision_state (self) | |
| test_check_self_collision_state (self) | |
Public Attributes | |
| robot_model = get_robot_model() | |
| scene = PlanningScene(self.robot_model) | |
| state = RobotState(self.robot_model) | |
Detailed Description
The collision checks release the GIL, so other Python threads keep running during bulk checks.
Definition at line 56 of file test_planning_scene.py.
Member Function Documentation
◆ assert_releases_gil()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.assert_releases_gil | ( | self, | |
| call ) |
Definition at line 69 of file test_planning_scene.py.
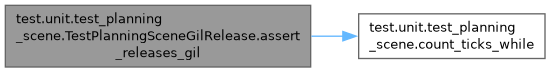
Here is the call graph for this function:
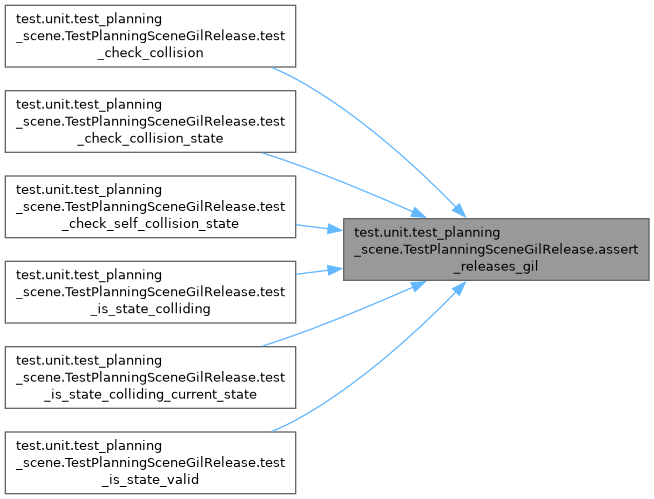
Here is the caller graph for this function:
◆ setUp()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.setUp | ( | self | ) |
Definition at line 63 of file test_planning_scene.py.
◆ setUpClass()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.setUpClass | ( | cls | ) |
Definition at line 60 of file test_planning_scene.py.
◆ test_check_collision()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.test_check_collision | ( | self | ) |

◆ test_check_collision_state()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.test_check_collision_state | ( | self | ) |

◆ test_check_self_collision_state()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.test_check_self_collision_state | ( | self | ) |

◆ test_is_state_colliding()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.test_is_state_colliding | ( | self | ) |

◆ test_is_state_colliding_current_state()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.test_is_state_colliding_current_state | ( | self | ) |

◆ test_is_state_valid()
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.test_is_state_valid | ( | self | ) |

Member Data Documentation
◆ robot_model
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.robot_model = get_robot_model() |
Definition at line 61 of file test_planning_scene.py.
◆ scene
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.scene = PlanningScene(self.robot_model) |
Definition at line 64 of file test_planning_scene.py.
◆ state
| test.unit.test_planning_scene.TestPlanningSceneGilRelease.state = RobotState(self.robot_model) |
Definition at line 65 of file test_planning_scene.py.
The documentation for this class was generated from the following file:
- moveit_py/test/unit/test_planning_scene.py
Generated by
 1.15.0