Classes | |
| class | TestPlanningSceneGilRelease |
Functions | |
| get_robot_model () | |
| count_ticks_while (call, duration=0.5) | |
Variables | |
| dir_path = os.path.dirname(os.path.realpath(__file__)) | |
| str | URDF_FILE = "{}/fixtures/panda.urdf".format(dir_path) |
| str | SRDF_FILE = "{}/fixtures/panda.srdf".format(dir_path) |
| str | GROUP = "panda_arm" |
Function Documentation
◆ count_ticks_while()
| test.unit.test_planning_scene.count_ticks_while | ( | call, | |
| duration = 0.5 ) |
Run call() in a loop for duration seconds and count how often another Python thread gets to run meanwhile.

The switch interval is raised far above duration, so the interpreter does not hand the GIL to the other
thread on its own: the other thread only runs while call() releases the GIL.
Definition at line 24 of file test_planning_scene.py.
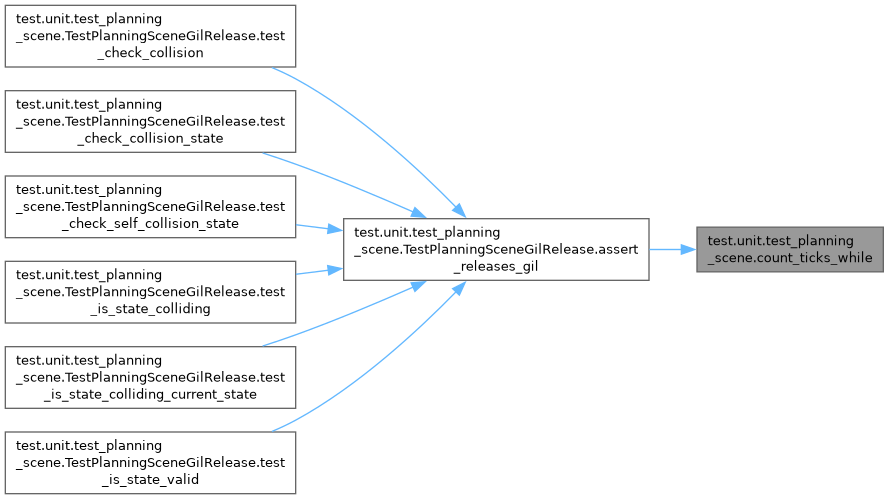
Here is the caller graph for this function:
◆ get_robot_model()
| test.unit.test_planning_scene.get_robot_model | ( | ) |
Helper function that returns a RobotModel instance.
Definition at line 19 of file test_planning_scene.py.
Variable Documentation
◆ dir_path
| test.unit.test_planning_scene.dir_path = os.path.dirname(os.path.realpath(__file__)) |
Definition at line 12 of file test_planning_scene.py.
◆ GROUP
| str test.unit.test_planning_scene.GROUP = "panda_arm" |
Definition at line 16 of file test_planning_scene.py.
◆ SRDF_FILE
| str test.unit.test_planning_scene.SRDF_FILE = "{}/fixtures/panda.srdf".format(dir_path) |
Definition at line 14 of file test_planning_scene.py.
◆ URDF_FILE
| str test.unit.test_planning_scene.URDF_FILE = "{}/fixtures/panda.urdf".format(dir_path) |
Definition at line 13 of file test_planning_scene.py.
Generated by
 1.15.0