robot_trajectory.cpp File Reference
#include "robot_trajectory.hpp"#include <moveit_py/moveit_py_utils/ros_msg_typecasters.hpp>#include <moveit/trajectory_processing/trajectory_tools.hpp>
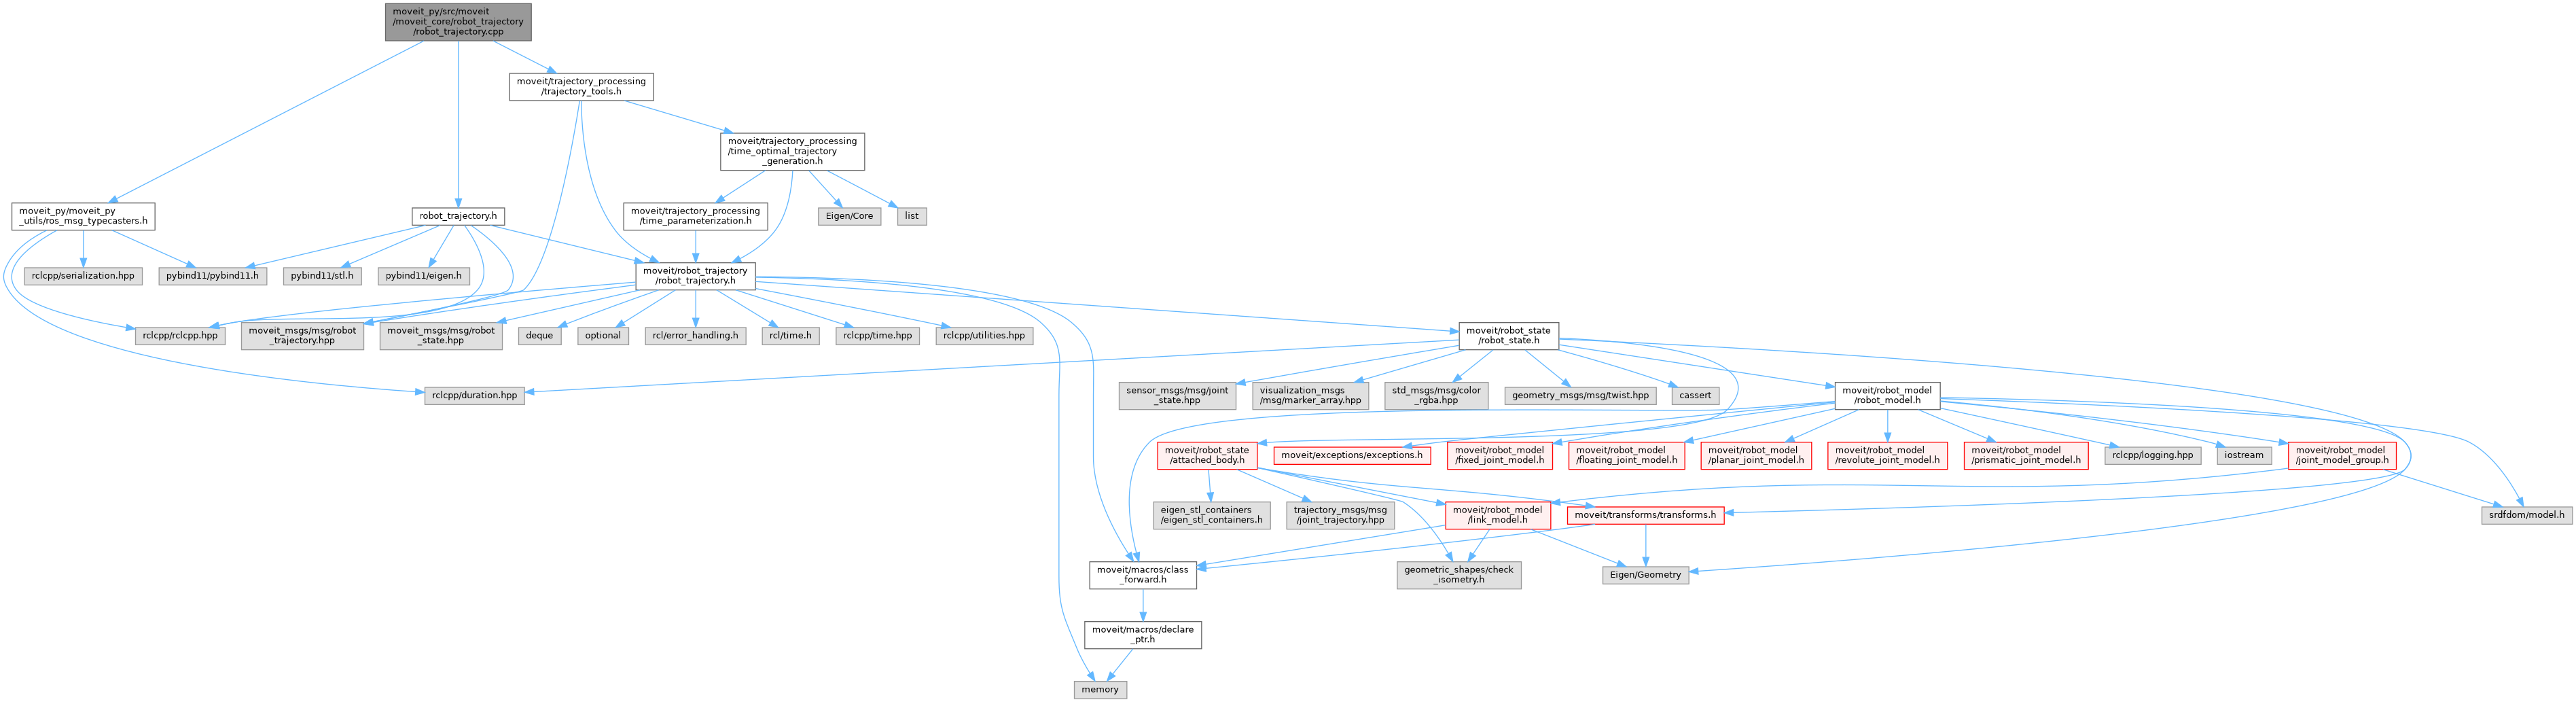
Include dependency graph for robot_trajectory.cpp:
Go to the source code of this file.
Namespaces | |
| namespace | moveit_py |
| namespace | moveit_py::bind_robot_trajectory |
Functions | |
| moveit_msgs::msg::RobotTrajectory | moveit_py::bind_robot_trajectory::getRobotTrajectoryMsg (const robot_trajectory::RobotTrajectoryConstPtr &robot_trajectory, const std::vector< std::string > &joint_filter) |
| robot_trajectory::RobotTrajectory | moveit_py::bind_robot_trajectory::setRobotTrajectoryMsg (const std::shared_ptr< robot_trajectory::RobotTrajectory > &robot_trajectory, const moveit::core::RobotState &robot_state, const moveit_msgs::msg::RobotTrajectory &msg) |
| void | moveit_py::bind_robot_trajectory::initRobotTrajectory (py::module &m) |
Generated by
 1.15.0