kdl_kinematics_plugin::internal Namespace Reference
Functions | |
| Eigen::VectorXd | solvePseudoinverse (const Eigen::Ref< const Eigen::MatrixXd > &jacobian, const Eigen::Ref< const Eigen::VectorXd > &input, double threshold) |
Function Documentation
◆ solvePseudoinverse()
|
inline |
Solve the minimum-norm system 
IK Jacobians have at most six rows and usually more columns. Decomposing the small symmetric 

Definition at line 18 of file pseudoinverse.hpp.
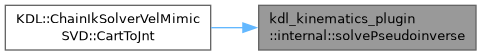
Here is the caller graph for this function:
Generated by
 1.15.0