pseudoinverse.hpp File Reference
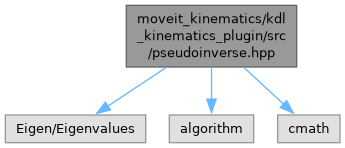
#include <Eigen/Eigenvalues>#include <algorithm>#include <cmath>
Include dependency graph for pseudoinverse.hpp:
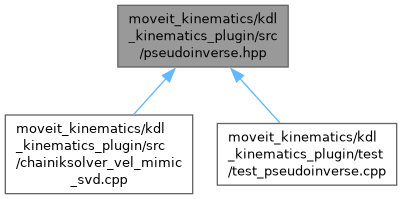
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Namespaces | |
| namespace | kdl_kinematics_plugin |
| namespace | kdl_kinematics_plugin::internal |
Functions | |
| Eigen::VectorXd | kdl_kinematics_plugin::internal::solvePseudoinverse (const Eigen::Ref< const Eigen::MatrixXd > &jacobian, const Eigen::Ref< const Eigen::VectorXd > &input, double threshold) |
Generated by
 1.15.0