test_logger.cpp File Reference
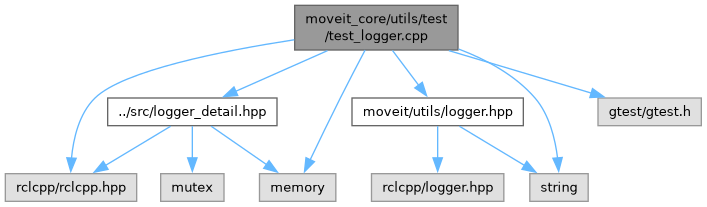
#include "../src/logger_detail.hpp"#include <moveit/utils/logger.hpp>#include <gtest/gtest.h>#include <rclcpp/rclcpp.hpp>#include <memory>#include <string>
Include dependency graph for test_logger.cpp:
Go to the source code of this file.
Functions | |
| int | main (int argc, char **argv) |
Function Documentation
◆ main()
| int main | ( | int | argc, |
| char ** | argv ) |
Definition at line 227 of file test_logger.cpp.
Generated by
 1.15.0