TrajectoryFunctionsTestFlangeAndGripper Class Reference
Parametrized class for tests with and without gripper. More...
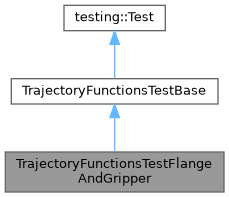
Inheritance diagram for TrajectoryFunctionsTestFlangeAndGripper:
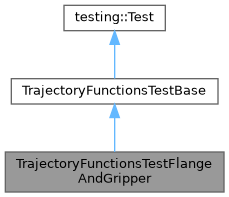
Collaboration diagram for TrajectoryFunctionsTestFlangeAndGripper:
Additional Inherited Members | |
| Protected Member Functions inherited from TrajectoryFunctionsTestBase | |
| void | SetUp () override |
| Create test scenario for trajectory functions. | |
| void | TearDown () override |
| bool | tfNear (const Eigen::Isometry3d &pose1, const Eigen::Isometry3d &pose2, double epsilon) |
| check if two transformations are close | |
| bool | jointsNear (const std::vector< double > &joints1, const std::vector< double > &joints2, double epsilon) |
| check if two sets of joint positions are close | |
| std::vector< double > | getJoints (const moveit::core::JointModelGroup *jmg, const moveit::core::RobotState &state) |
| get the current joint values of the robot state | |
| void | attachToLink (moveit::core::RobotState &state, const moveit::core::LinkModel *link, const std::string &object_name, const Eigen::Isometry3d &object_pose, const moveit::core::FixedTransformsMap &subframes) |
| attach a collision object and subframes to a link | |
| Protected Attributes inherited from TrajectoryFunctionsTestBase | |
| rclcpp::Node::SharedPtr | node_ |
| moveit::core::RobotModelConstPtr | robot_model_ |
| moveit::core::RobotStatePtr | robot_state_ |
| std::unique_ptr< robot_model_loader::RobotModelLoader > | rm_loader_ |
| planning_scene::PlanningSceneConstPtr | planning_scene_ |
| std::string | planning_group_ |
| std::string | group_tip_link_ |
| std::string | tcp_link_ |
| std::string | ik_fast_link_ |
| int | random_test_number_ |
| std::vector< std::string > | joint_names_ |
| std::map< std::string, double > | zero_state_ |
| uint32_t | random_seed_ { 100 } |
| random_numbers::RandomNumberGenerator | rng_ { random_seed_ } |
Detailed Description
Parametrized class for tests with and without gripper.
Definition at line 236 of file unittest_trajectory_functions.cpp.
The documentation for this class was generated from the following file:
- moveit_planners/pilz_industrial_motion_planner/test/unit_tests/src/unittest_trajectory_functions.cpp
Generated by
 1.15.0