replan_invalidated_trajectory.cpp File Reference
#include <moveit/local_planner/feedback_types.hpp>#include <moveit/planner_logic_plugins/replan_invalidated_trajectory.hpp>#include <pluginlib/class_list_macros.hpp>
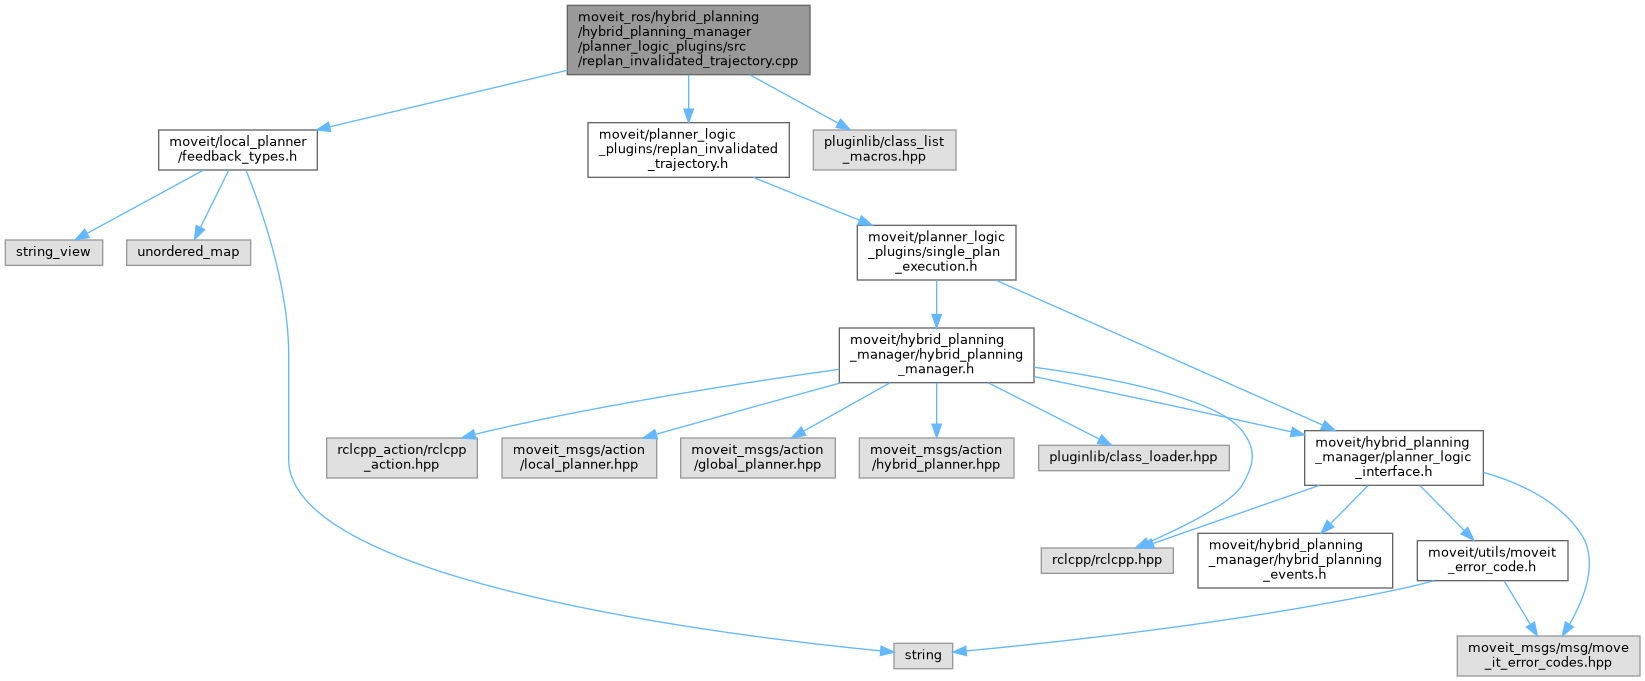
Include dependency graph for replan_invalidated_trajectory.cpp:
Go to the source code of this file.
Namespaces | |
| namespace | moveit |
| Main namespace for MoveIt. | |
| namespace | moveit::hybrid_planning |
Generated by
 1.15.0