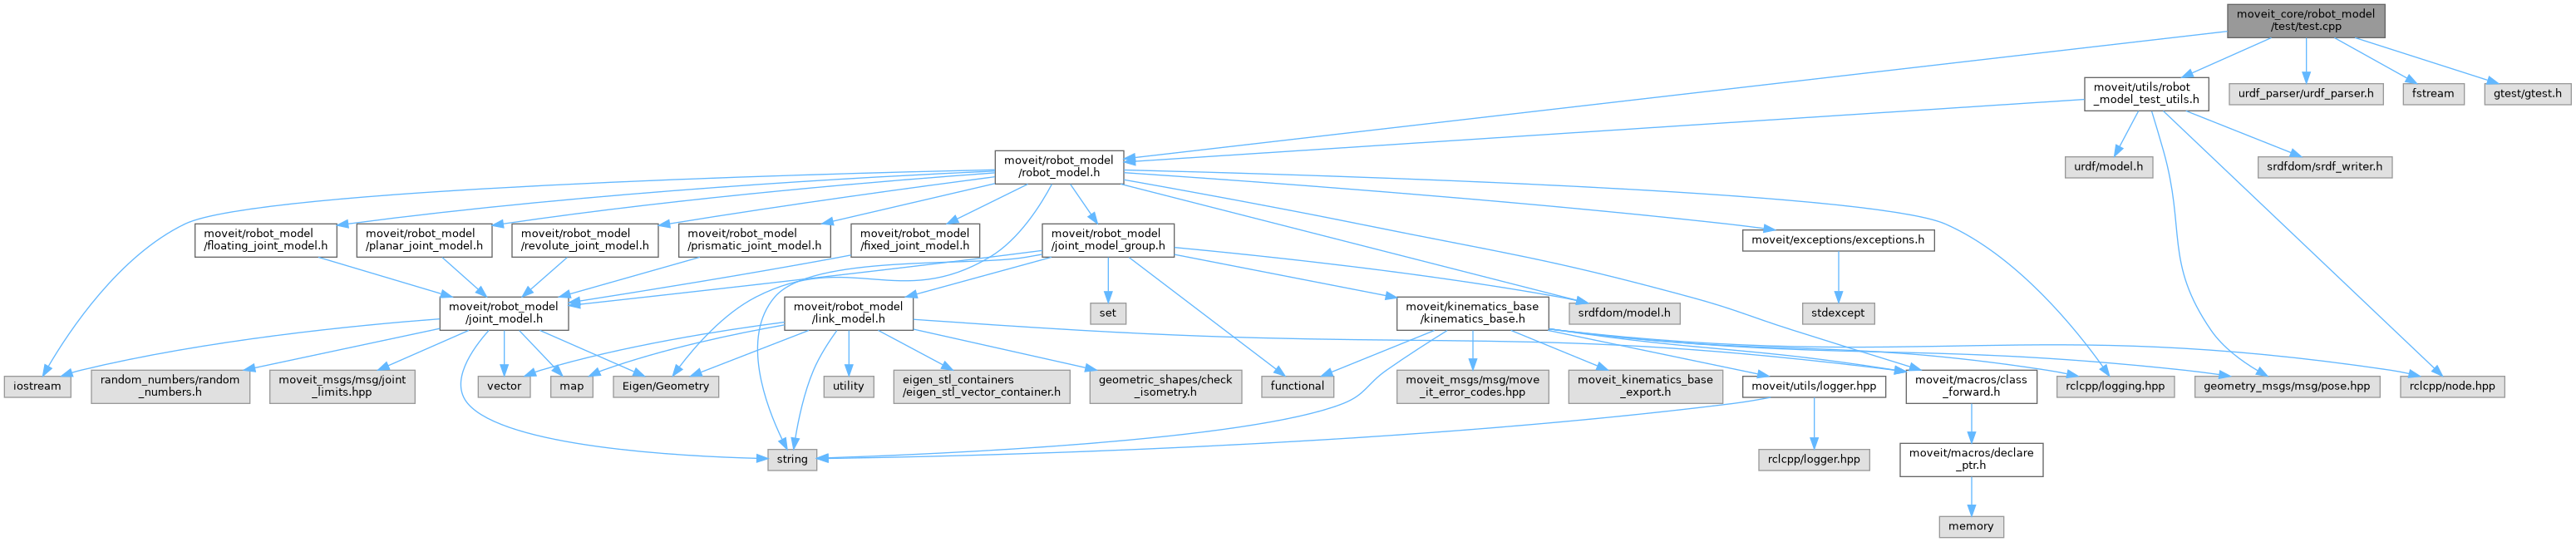
#include <moveit/robot_model/robot_model.hpp>
#include <urdf_parser/urdf_parser.h>
#include <fstream>
#include <gtest/gtest.h>
#include <moveit/utils/robot_model_test_utils.hpp>
Go to the source code of this file.
◆ main()
| int main |
( |
int | argc, |
|
|
char ** | argv ) |
◆ TEST() [1/4]
| TEST |
( |
FloatingJointTest | , |
|
|
interpolation_test | ) |
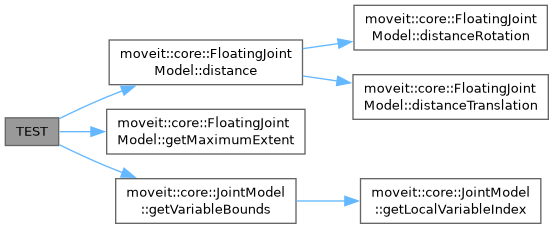
◆ TEST() [2/4]
| TEST |
( |
FloatingJointTest | , |
|
|
maximum_extent_test | ) |
◆ TEST() [3/4]
| TEST |
( |
PlanarJointTest | , |
|
|
ComputeVariablePositionsNormalizeYaw | ) |
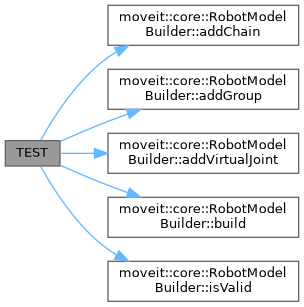
◆ TEST() [4/4]
| TEST |
( |
SiblingAssociateLinks | , |
|
|
SimpleYRobot | ) |
◆ TEST_F() [1/2]
◆ TEST_F() [2/2]

 1.15.0