#include <simple_sampler.hpp>
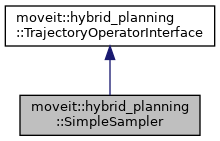
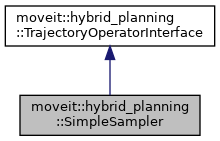
Public Member Functions | |
| SimpleSampler ()=default | |
| ~SimpleSampler () override=default | |
| bool | initialize (const rclcpp::Node::SharedPtr &node, const moveit::core::RobotModelConstPtr &robot_model, const std::string &group_name) override |
| moveit_msgs::action::LocalPlanner::Feedback | addTrajectorySegment (const robot_trajectory::RobotTrajectory &new_trajectory) override |
| moveit_msgs::action::LocalPlanner::Feedback | getLocalTrajectory (const moveit::core::RobotState ¤t_state, robot_trajectory::RobotTrajectory &local_trajectory) override |
| double | getTrajectoryProgress (const moveit::core::RobotState ¤t_state) override |
| bool | reset () override |
| Public Member Functions inherited from moveit::hybrid_planning::TrajectoryOperatorInterface | |
| TrajectoryOperatorInterface ()=default | |
| TrajectoryOperatorInterface (const TrajectoryOperatorInterface &)=default | |
| TrajectoryOperatorInterface (TrajectoryOperatorInterface &&)=default | |
| TrajectoryOperatorInterface & | operator= (const TrajectoryOperatorInterface &)=default |
| TrajectoryOperatorInterface & | operator= (TrajectoryOperatorInterface &&)=default |
| virtual | ~TrajectoryOperatorInterface ()=default |
Additional Inherited Members | |
| Protected Attributes inherited from moveit::hybrid_planning::TrajectoryOperatorInterface | |
| robot_trajectory::RobotTrajectoryPtr | reference_trajectory_ |
| std::string | group_ |
Detailed Description
Definition at line 48 of file simple_sampler.hpp.
Constructor & Destructor Documentation
◆ SimpleSampler()
|
default |
◆ ~SimpleSampler()
|
overridedefault |
Member Function Documentation
◆ addTrajectorySegment()
|
overridevirtual |
Add a new reference trajectory segment to the vector of global trajectory segments to process
- Parameters
-
new_trajectory New reference trajectory segment to add
- Returns
- True if segment was successfully added
Implements moveit::hybrid_planning::TrajectoryOperatorInterface.
Definition at line 56 of file simple_sampler.cpp.

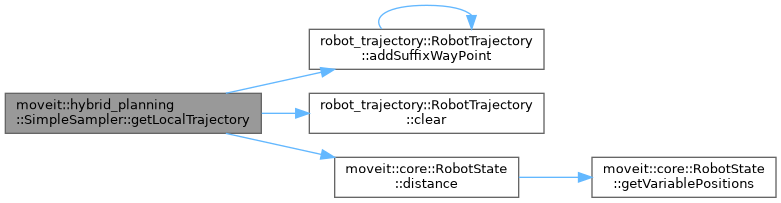
◆ getLocalTrajectory()
|
overridevirtual |
Return the current local constraints based on the newest robot state
- Parameters
-
current_state Current RobotState
- Returns
- Current local constraints that define the local planning goal
Implements moveit::hybrid_planning::TrajectoryOperatorInterface.
Definition at line 79 of file simple_sampler.cpp.
◆ getTrajectoryProgress()
|
overridevirtual |
Return the processing status of the reference trajectory's execution based on a user defined metric.
- Parameters
-
current_state Current RobotState
- Returns
- A value between 0.0 (start) to 1.0 (completion).
Implements moveit::hybrid_planning::TrajectoryOperatorInterface.
Definition at line 109 of file simple_sampler.cpp.
◆ initialize()
|
overridevirtual |
Initialize trajectory operator
- Parameters
-
node Node handle to access parameters robot_model Robot model group_name Name of the joint group the trajectory uses
- Returns
- True if initialization was successful
Implements moveit::hybrid_planning::TrajectoryOperatorInterface.
Definition at line 46 of file simple_sampler.cpp.
◆ reset()
|
overridevirtual |
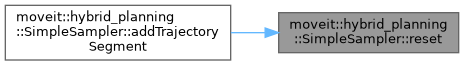
Reset trajectory operator to some user-defined initial state
- Returns
- True if reset was successful
Implements moveit::hybrid_planning::TrajectoryOperatorInterface.
Definition at line 71 of file simple_sampler.cpp.
The documentation for this class was generated from the following files:
- moveit_ros/hybrid_planning/local_planner/trajectory_operator_plugins/include/moveit/trajectory_operator_plugins/simple_sampler.hpp
- moveit_ros/hybrid_planning/local_planner/trajectory_operator_plugins/src/simple_sampler.cpp
Generated by
 1.15.0