ompl_interface::ConstraintsLibrary Class Reference
#include <constraints_library.hpp>
Public Member Functions | |
| ConstraintsLibrary (ModelBasedPlanningContext *pcontext) | |
| void | loadConstraintApproximations (const std::string &path) |
| void | saveConstraintApproximations (const std::string &path) |
| ConstraintApproximationConstructionResults | addConstraintApproximation (const moveit_msgs::msg::Constraints &constr_sampling, const moveit_msgs::msg::Constraints &constr_hard, const std::string &group, const planning_scene::PlanningSceneConstPtr &scene, const ConstraintApproximationConstructionOptions &options) |
| ConstraintApproximationConstructionResults | addConstraintApproximation (const moveit_msgs::msg::Constraints &constr, const std::string &group, const planning_scene::PlanningSceneConstPtr &scene, const ConstraintApproximationConstructionOptions &options) |
| void | printConstraintApproximations (std::ostream &out=std::cout) const |
| void | clearConstraintApproximations () |
| void | registerConstraintApproximation (const ConstraintApproximationPtr &approx) |
| const ConstraintApproximationPtr & | getConstraintApproximation (const moveit_msgs::msg::Constraints &msg) const |
Detailed Description
Definition at line 161 of file constraints_library.hpp.
Constructor & Destructor Documentation
◆ ConstraintsLibrary()
|
inline |
Definition at line 164 of file constraints_library.hpp.
Member Function Documentation
◆ addConstraintApproximation() [1/2]
| ConstraintApproximationConstructionResults ompl_interface::ConstraintsLibrary::addConstraintApproximation | ( | const moveit_msgs::msg::Constraints & | constr, |
| const std::string & | group, | ||
| const planning_scene::PlanningSceneConstPtr & | scene, | ||
| const ConstraintApproximationConstructionOptions & | options ) |
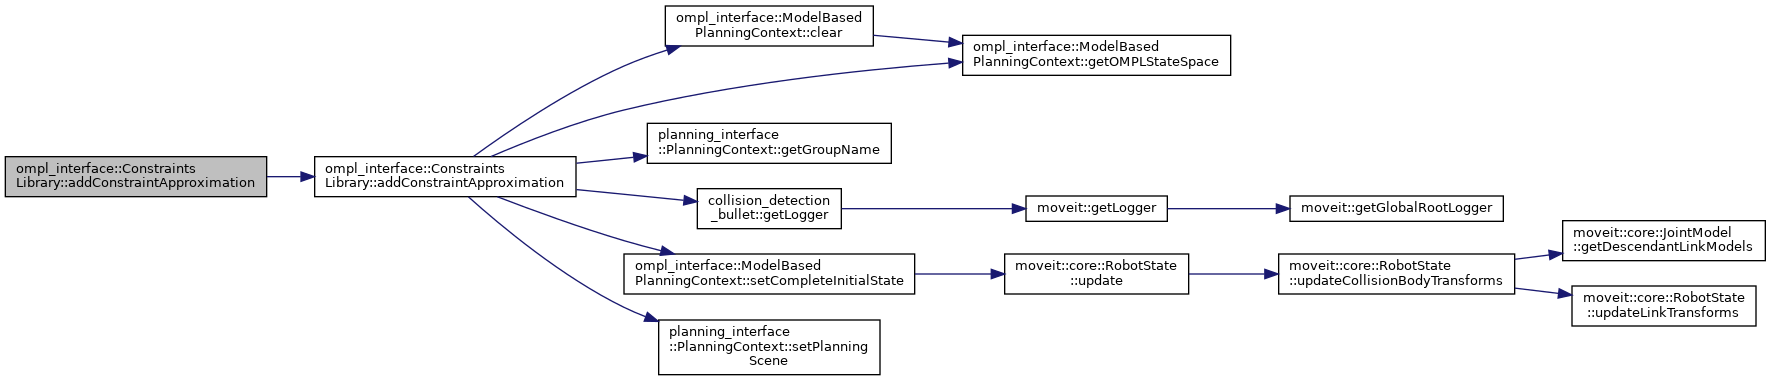
◆ addConstraintApproximation() [2/2]
| ConstraintApproximationConstructionResults ompl_interface::ConstraintsLibrary::addConstraintApproximation | ( | const moveit_msgs::msg::Constraints & | constr_sampling, |
| const moveit_msgs::msg::Constraints & | constr_hard, | ||
| const std::string & | group, | ||
| const planning_scene::PlanningSceneConstPtr & | scene, | ||
| const ConstraintApproximationConstructionOptions & | options ) |
Definition at line 424 of file constraints_library.cpp.
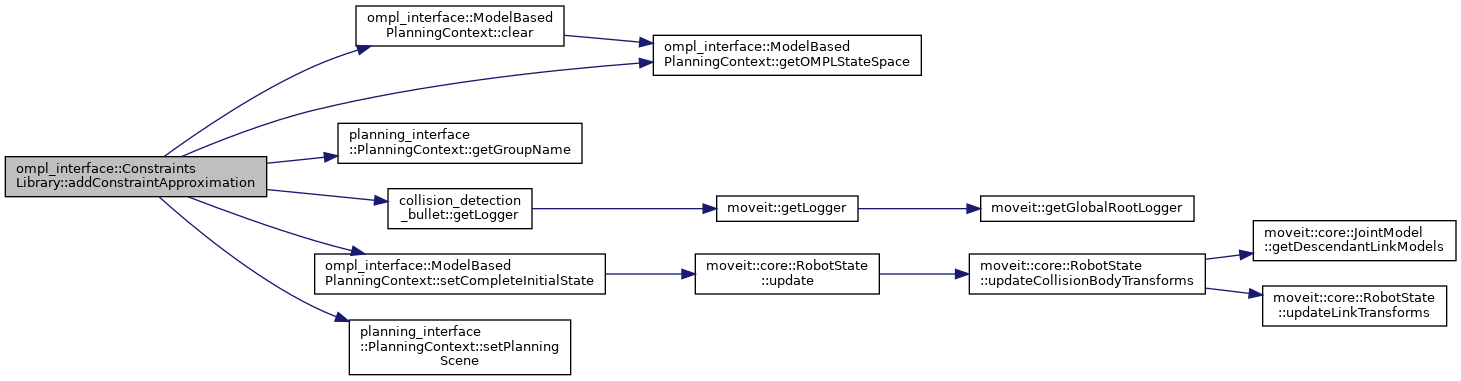
Here is the call graph for this function:
Here is the caller graph for this function:

◆ clearConstraintApproximations()
| void ompl_interface::ConstraintsLibrary::clearConstraintApproximations | ( | ) |
Definition at line 385 of file constraints_library.cpp.
◆ getConstraintApproximation()
| const ConstraintApproximationPtr & ompl_interface::ConstraintsLibrary::getConstraintApproximation | ( | const moveit_msgs::msg::Constraints & | msg | ) | const |
Definition at line 406 of file constraints_library.cpp.
◆ loadConstraintApproximations()
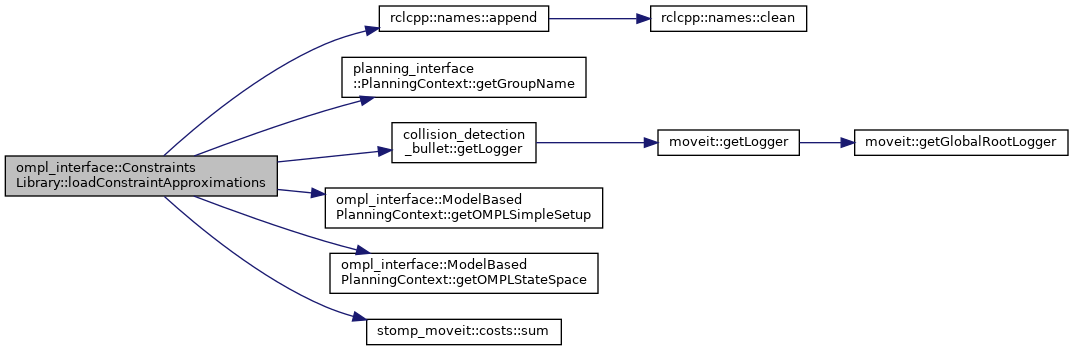
| void ompl_interface::ConstraintsLibrary::loadConstraintApproximations | ( | const std::string & | path | ) |
◆ printConstraintApproximations()
| void ompl_interface::ConstraintsLibrary::printConstraintApproximations | ( | std::ostream & | out = std::cout | ) | const |
Definition at line 390 of file constraints_library.cpp.
◆ registerConstraintApproximation()
|
inline |
Definition at line 186 of file constraints_library.hpp.
◆ saveConstraintApproximations()
| void ompl_interface::ConstraintsLibrary::saveConstraintApproximations | ( | const std::string & | path | ) |

The documentation for this class was generated from the following files:
- moveit_planners/ompl/ompl_interface/include/moveit/ompl_interface/detail/constraints_library.hpp
- moveit_planners/ompl/ompl_interface/src/detail/constraints_library.cpp
Generated by
 1.15.0