moveit2
The MoveIt Motion Planning Framework for ROS 2.
Loading...
Searching...
No Matches
ompl_interface::PoseModelStateSpace Class Reference

#include <pose_model_state_space.hpp>

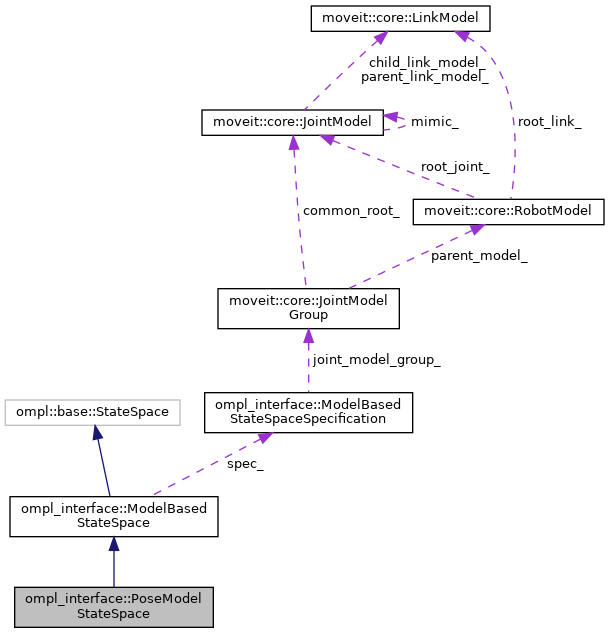
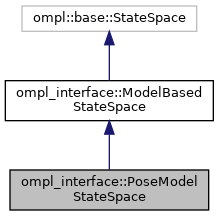
Inheritance diagram for ompl_interface::PoseModelStateSpace:
Collaboration diagram for ompl_interface::PoseModelStateSpace:

Classes

class  StateType

Public Member Functions

 PoseModelStateSpace (const ModelBasedStateSpaceSpecification &spec)
 ~PoseModelStateSpace () override
ompl::base::State * allocState () const override
void freeState (ompl::base::State *state) const override
void copyState (ompl::base::State *destination, const ompl::base::State *source) const override
void interpolate (const ompl::base::State *from, const ompl::base::State *to, const double t, ompl::base::State *state) const override
double distance (const ompl::base::State *state1, const ompl::base::State *state2) const override
double getMaximumExtent () const override
ompl::base::StateSamplerPtr allocDefaultStateSampler () const override
bool computeStateFK (ompl::base::State *state) const
bool computeStateIK (ompl::base::State *state) const
bool computeStateK (ompl::base::State *state) const
void setPlanningVolume (double minX, double maxX, double minY, double maxY, double minZ, double maxZ) override
 Set the planning volume for the possible SE2 and/or SE3 components of the state space.
void copyToOMPLState (ompl::base::State *state, const moveit::core::RobotState &rstate) const override
 Copy the data from a set of joint states to an OMPL state.
void sanityChecks () const override
const std::string & getParameterizationType () const override
Public Member Functions inherited from ompl_interface::ModelBasedStateSpace
 ModelBasedStateSpace (ModelBasedStateSpaceSpecification spec)
 ~ModelBasedStateSpace () override
void setInterpolationFunction (const InterpolationFunction &fun)
void setDistanceFunction (const DistanceFunction &fun)
ompl::base::State * allocState () const override
void freeState (ompl::base::State *state) const override
unsigned int getDimension () const override
void enforceBounds (ompl::base::State *state) const override
bool satisfiesBounds (const ompl::base::State *state) const override
void copyState (ompl::base::State *destination, const ompl::base::State *source) const override
void interpolate (const ompl::base::State *from, const ompl::base::State *to, const double t, ompl::base::State *state) const override
double distance (const ompl::base::State *state1, const ompl::base::State *state2) const override
bool equalStates (const ompl::base::State *state1, const ompl::base::State *state2) const override
double getMaximumExtent () const override
double getMeasure () const override
unsigned int getSerializationLength () const override
void serialize (void *serialization, const ompl::base::State *state) const override
void deserialize (ompl::base::State *state, const void *serialization) const override
double * getValueAddressAtIndex (ompl::base::State *state, const unsigned int index) const override
ompl::base::StateSamplerPtr allocDefaultStateSampler () const override
const moveit::core::RobotModelConstPtr & getRobotModel () const
const moveit::core::JointModelGroupgetJointModelGroup () const
const std::string & getJointModelGroupName () const
const ModelBasedStateSpaceSpecificationgetSpecification () const
void printState (const ompl::base::State *state, std::ostream &out) const override
void printSettings (std::ostream &out) const override
const moveit::core::JointBoundsVectorgetJointsBounds () const
virtual void copyToRobotState (moveit::core::RobotState &rstate, const ompl::base::State *state) const
 Copy the data from an OMPL state to a set of joint states.
virtual void copyJointToOMPLState (ompl::base::State *state, const moveit::core::RobotState &robot_state, const moveit::core::JointModel *joint_model, int ompl_state_joint_index) const
 Copy a single joint's values (which might have multiple variables) from a MoveIt robot_state to an OMPL state.
double getTagSnapToSegment () const
void setTagSnapToSegment (double snap)

Static Public Attributes

static const std::string PARAMETERIZATION_TYPE = "PoseModel"

Additional Inherited Members

Protected Attributes inherited from ompl_interface::ModelBasedStateSpace
ModelBasedStateSpaceSpecification spec_
std::vector< moveit::core::JointModel::Boundsjoint_bounds_storage_
std::vector< const moveit::core::JointModel * > joint_model_vector_
unsigned int variable_count_
size_t state_values_size_
InterpolationFunction interpolation_function_
DistanceFunction distance_function_
double tag_snap_to_segment_
double tag_snap_to_segment_complement_

Detailed Description

Definition at line 44 of file pose_model_state_space.hpp.
Constructor & Destructor Documentation

◆ PoseModelStateSpace()

ompl_interface::PoseModelStateSpace::PoseModelStateSpace ( const ModelBasedStateSpaceSpecification & spec)

Definition at line 55 of file pose_model_state_space.cpp.

Here is the call graph for this function:
Here is the caller graph for this function:

◆ ~PoseModelStateSpace()

ompl_interface::PoseModelStateSpace::~PoseModelStateSpace ( )
overridedefault

Member Function Documentation

◆ allocDefaultStateSampler()

ompl::base::StateSamplerPtr ompl_interface::PoseModelStateSpace::allocDefaultStateSampler ( ) const
override

Definition at line 299 of file pose_model_state_space.cpp.

Here is the call graph for this function:

◆ allocState()

ompl::base::State * ompl_interface::PoseModelStateSpace::allocState ( ) const
override

Definition at line 96 of file pose_model_state_space.cpp.

◆ computeStateFK()

bool ompl_interface::PoseModelStateSpace::computeStateFK ( ompl::base::State * state) const

Definition at line 255 of file pose_model_state_space.cpp.

Here is the call graph for this function:
Here is the caller graph for this function:

◆ computeStateIK()

bool ompl_interface::PoseModelStateSpace::computeStateIK ( ompl::base::State * state) const

Definition at line 271 of file pose_model_state_space.cpp.

Here is the call graph for this function:
Here is the caller graph for this function:

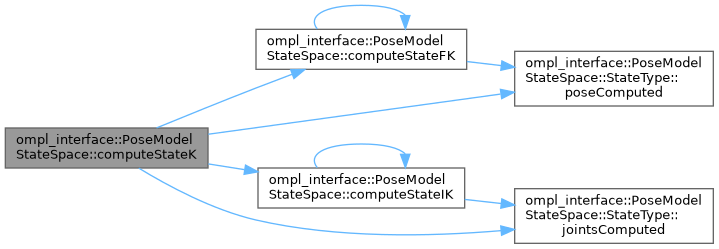
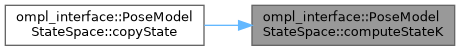
◆ computeStateK()

bool ompl_interface::PoseModelStateSpace::computeStateK ( ompl::base::State * state) const

Definition at line 287 of file pose_model_state_space.cpp.

Here is the call graph for this function:
Here is the caller graph for this function:

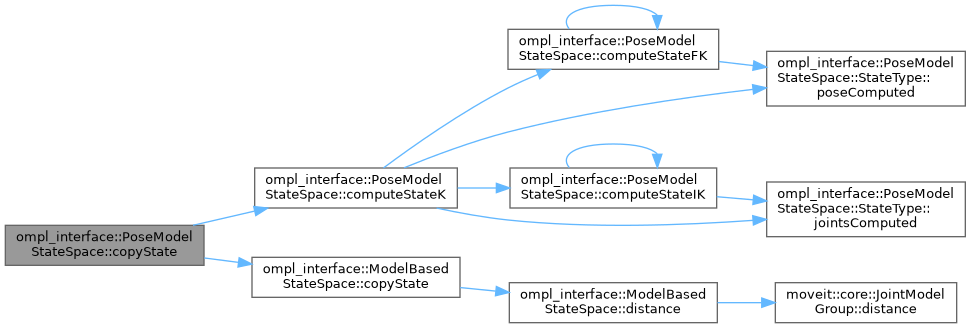
◆ copyState()

void ompl_interface::PoseModelStateSpace::copyState ( ompl::base::State * destination,
const ompl::base::State * source ) const
override

Definition at line 115 of file pose_model_state_space.cpp.

Here is the call graph for this function:

◆ copyToOMPLState()

void ompl_interface::PoseModelStateSpace::copyToOMPLState ( ompl::base::State * state,
const moveit::core::RobotState & rstate ) const
overridevirtual

Copy the data from a set of joint states to an OMPL state.

Reimplemented from ompl_interface::ModelBasedStateSpace.

Definition at line 342 of file pose_model_state_space.cpp.

Here is the call graph for this function:

◆ distance()

double ompl_interface::PoseModelStateSpace::distance ( const ompl::base::State * state1,
const ompl::base::State * state2 ) const
override

Definition at line 83 of file pose_model_state_space.cpp.

Here is the call graph for this function:
Here is the caller graph for this function:

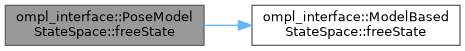
◆ freeState()

void ompl_interface::PoseModelStateSpace::freeState ( ompl::base::State * state) const
override

Definition at line 107 of file pose_model_state_space.cpp.

Here is the call graph for this function:

◆ getMaximumExtent()

double ompl_interface::PoseModelStateSpace::getMaximumExtent ( ) const
override

Definition at line 88 of file pose_model_state_space.cpp.

◆ getParameterizationType()

const std::string & ompl_interface::PoseModelStateSpace::getParameterizationType ( ) const
inlineoverridevirtual

Implements ompl_interface::ModelBasedStateSpace.

Definition at line 121 of file pose_model_state_space.hpp.

◆ interpolate()

void ompl_interface::PoseModelStateSpace::interpolate ( const ompl::base::State * from,
const ompl::base::State * to,
const double t,
ompl::base::State * state ) const
override

Definition at line 133 of file pose_model_state_space.cpp.

Here is the call graph for this function:

◆ sanityChecks()

void ompl_interface::PoseModelStateSpace::sanityChecks ( ) const
override

Definition at line 127 of file pose_model_state_space.cpp.

◆ setPlanningVolume()

void ompl_interface::PoseModelStateSpace::setPlanningVolume ( double minX,
double maxX,
double minY,
double maxY,
double minZ,
double maxZ )
overridevirtual

Set the planning volume for the possible SE2 and/or SE3 components of the state space.

Reimplemented from ompl_interface::ModelBasedStateSpace.

Definition at line 163 of file pose_model_state_space.cpp.

Here is the call graph for this function:

Member Data Documentation

◆ PARAMETERIZATION_TYPE

const std::string ompl_interface::PoseModelStateSpace::PARAMETERIZATION_TYPE = "PoseModel"
static

Definition at line 47 of file pose_model_state_space.hpp.


The documentation for this class was generated from the following files: