#include <chainiksolver_vel_mimic_svd.hpp>
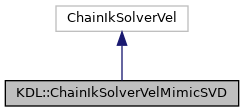
Public Member Functions | |
| ChainIkSolverVelMimicSVD (const Chain &chain_, const std::vector< kdl_kinematics_plugin::JointMimic > &mimic_joints, bool position_ik=false, double threshold=0.001) | |
| void | updateInternalDataStructures () override |
| ~ChainIkSolverVelMimicSVD () override | |
| int | CartToJnt (const JntArray &q_in, const Twist &v_in, JntArray &qdot_out) override |
| int | CartToJnt (const JntArray &q_in, const Twist &v_in, JntArray &qdot_out, const Eigen::VectorXd &joint_weights, const Eigen::Matrix< double, 6, 1 > &cartesian_weights) |
| int | CartToJnt (const JntArray &, const FrameVel &, JntArrayVel &) override |
| not implemented. | |
| bool | isPositionOnly () const |
| Return true iff we ignore orientation but only consider position for inverse kinematics. | |
Detailed Description
Implementation of an inverse velocity kinematics algorithm based on the generalized pseudoinverse to calculate the velocity transformation from Cartesian to joint space of a general KDL::Chain.
Definition at line 45 of file chainiksolver_vel_mimic_svd.hpp.
Constructor & Destructor Documentation
◆ ChainIkSolverVelMimicSVD()
|
explicit |
Constructor of the solver
- Parameters
-
chain the chain to calculate the inverse velocity kinematics for mimic_joints A vector of indices that map each (and every) joint onto the corresponding joint in a reduced set of joints that do not include the mimic joints. This vector must be of size chain.getNrOfJoints(). E.g. if an arm has 7 joints: j0 to j6. Say j2 mimics (follows) j0. Then, mimic_joints should be: [0 1 0 3 4 5 6] num_mimic_joints The number of joints that are setup to follow other joints position_ik false if you want to solve for the full 6 dof end-effector pose, true if you want to solve only for the 3 dof end-effector position. threshold if a singular value is below this value, its inverse is set to zero, default: 0.001
Definition at line 46 of file chainiksolver_vel_mimic_svd.cpp.
◆ ~ChainIkSolverVelMimicSVD()
|
overridedefault |
Member Function Documentation
◆ CartToJnt() [1/3]
|
inlineoverride |
not implemented.
Definition at line 83 of file chainiksolver_vel_mimic_svd.hpp.
◆ CartToJnt() [2/3]
|
inlineoverride |
Definition at line 68 of file chainiksolver_vel_mimic_svd.hpp.
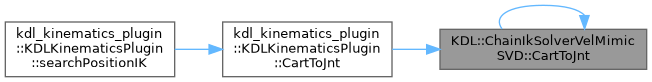
◆ CartToJnt() [3/3]
| int KDL::ChainIkSolverVelMimicSVD::CartToJnt | ( | const JntArray & | q_in, |
| const Twist & | v_in, | ||
| JntArray & | qdot_out, | ||
| const Eigen::VectorXd & | joint_weights, | ||
| const Eigen::Matrix< double, 6, 1 > & | cartesian_weights ) |
Compute qdot_out = W_q * (W_x * J * W_q)^# * W_x * v_in
where W_q and W_x are joint- and Cartesian weights respectively. A smaller joint weight (< 1.0) will reduce the contribution of this joint to the solution.
Definition at line 87 of file chainiksolver_vel_mimic_svd.cpp.
◆ isPositionOnly()
|
inline |
Return true iff we ignore orientation but only consider position for inverse kinematics.
Definition at line 89 of file chainiksolver_vel_mimic_svd.hpp.

◆ updateInternalDataStructures()
|
override |
Definition at line 65 of file chainiksolver_vel_mimic_svd.cpp.
The documentation for this class was generated from the following files:
- moveit_kinematics/kdl_kinematics_plugin/include/moveit/kdl_kinematics_plugin/chainiksolver_vel_mimic_svd.hpp
- moveit_kinematics/kdl_kinematics_plugin/src/chainiksolver_vel_mimic_svd.cpp
Generated by
 1.15.0