ikfast::IkSolution< T > Class Template Reference
Default implementation of IkSolutionBase. More...
#include <ikfast.h>
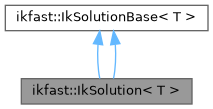
Inheritance diagram for ikfast::IkSolution< T >:
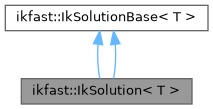
Collaboration diagram for ikfast::IkSolution< T >:
Public Member Functions | |
| IkSolution (const std::vector< IkSingleDOFSolutionBase< T > > &vinfos, const std::vector< int > &vfree) | |
| virtual void | GetSolution (T *solution, const T *freevalues) const |
| gets a concrete solution | |
| virtual void | GetSolution (std::vector< T > &solution, const std::vector< T > &freevalues) const |
| std::vector version of GetSolution | |
| virtual const std::vector< int > & | GetFree () const |
| Gets the indices of the configuration space that have to be preset before a full solution can be returned. | |
| virtual int | GetDOF () const |
| the dof of the solution | |
| virtual void | Validate () const |
| virtual void | GetSolutionIndices (std::vector< unsigned int > &v) const |
| Public Member Functions inherited from ikfast::IkSolutionBase< T > | |
| virtual | ~IkSolutionBase () |
Public Attributes | |
| std::vector< IkSingleDOFSolutionBase< T > > | _vbasesol |
| solution and their offsets if joints are mimicked | |
| std::vector< int > | _vfree |
Detailed Description
template<typename T>
class ikfast::IkSolution< T >
class ikfast::IkSolution< T >
Default implementation of IkSolutionBase.
Constructor & Destructor Documentation
◆ IkSolution()
template<typename T>
|
inline |
Member Function Documentation
◆ GetDOF()
template<typename T>
|
inlinevirtual |
the dof of the solution
Implements ikfast::IkSolutionBase< T >.
Definition at line 208 of file ikfast.h.
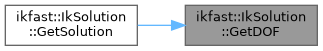
Here is the caller graph for this function:
◆ GetFree()
template<typename T>
|
inlinevirtual |
Gets the indices of the configuration space that have to be preset before a full solution can be returned.
- Returns
- vector of indices indicating the free parameters
Implements ikfast::IkSolutionBase< T >.
◆ GetSolution() [1/2]
template<typename T>
|
inlinevirtual |
std::vector version of GetSolution
Reimplemented from ikfast::IkSolutionBase< T >.
Definition at line 198 of file ikfast.h.
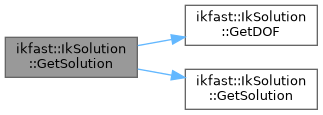
Here is the call graph for this function:
◆ GetSolution() [2/2]
template<typename T>
|
inlinevirtual |
gets a concrete solution
- Parameters
-
[out] solution the result [in] freevalues values for the free parameters \se GetFree
Implements ikfast::IkSolutionBase< T >.
Definition at line 177 of file ikfast.h.
Here is the caller graph for this function:
◆ GetSolutionIndices()
template<typename T>
|
inlinevirtual |
◆ Validate()
template<typename T>
|
inlinevirtual |
Member Data Documentation
◆ _vbasesol
template<typename T>
| std::vector<IkSingleDOFSolutionBase<T> > ikfast::IkSolution< T >::_vbasesol |
◆ _vfree
template<typename T>
| std::vector<int> ikfast::IkSolution< T >::_vfree |
The documentation for this class was generated from the following file:
- moveit_planners/test_configs/prbt_ikfast_manipulator_plugin/include/ikfast.h
Generated by
 1.15.0