create_readme_table Namespace Reference
Functions | |
| create_header (ros_ubuntu_dict) | |
| define_urls (target, params) | |
| create_line (package, ros_ubuntu_dict) | |
| create_moveit_buildfarm_table () | |
Function Documentation
◆ create_header()
| create_readme_table.create_header | ( | ros_ubuntu_dict | ) |
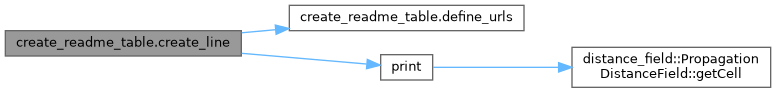
◆ create_line()
| create_readme_table.create_line | ( | package, | |
| ros_ubuntu_dict ) |
Definition at line 71 of file create_readme_table.py.
Here is the call graph for this function:
Here is the caller graph for this function:
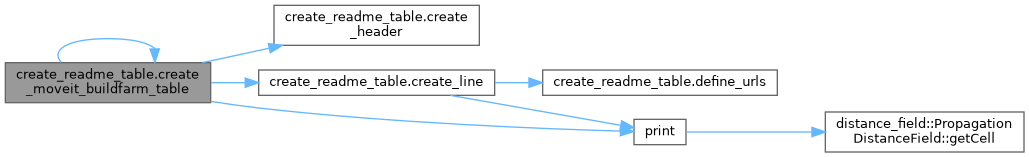
◆ create_moveit_buildfarm_table()
| create_readme_table.create_moveit_buildfarm_table | ( | ) |
Create MoveIt buildfarm badge table.
Definition at line 101 of file create_readme_table.py.
Here is the call graph for this function:
Here is the caller graph for this function:
◆ define_urls()
| create_readme_table.define_urls | ( | target, | |
| params ) |

Generated by
 1.15.0