Functions | |
| start_program (robot_name) | |
| test_sequence (initJointPose, L, M, planning_group, target_link, reference_frame, default_or, P1_position, P1_orientation) | |
Variables | |
| dict | robot_configs = {} |
| robots = list(robot_configs.keys()) | |
Function Documentation
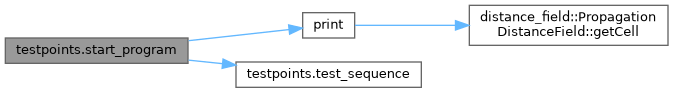
◆ start_program()
| testpoints.start_program | ( | robot_name | ) |
◆ test_sequence()
| testpoints.test_sequence | ( | initJointPose, | |
| L, | |||
| M, | |||
| planning_group, | |||
| target_link, | |||
| reference_frame, | |||
| default_or, | |||
| P1_position, | |||
| P1_orientation ) |

Variable Documentation
◆ robot_configs
| dict testpoints.robot_configs = {} |
Definition at line 42 of file testpoints.py.
◆ robots
| testpoints.robots = list(robot_configs.keys()) |
Definition at line 210 of file testpoints.py.
Generated by
 1.15.0