MyInfo Class Reference
Public Member Functions | |
| MyInfo () | |
| void | setThreadFunc (robot_interaction::LockedRobotState *locked_state, int *counter, double offset) |
| void | modifyThreadFunc (robot_interaction::LockedRobotState *locked_state, int *counter, double offset) |
| void | checkThreadFunc (robot_interaction::LockedRobotState *locked_state, int *counter) |
| void | waitThreadFunc (robot_interaction::LockedRobotState *locked_state, int **counters, int max) |
Detailed Description
Definition at line 302 of file locked_robot_state_test.cpp.
Constructor & Destructor Documentation
◆ MyInfo()
|
inline |
Definition at line 305 of file locked_robot_state_test.cpp.
Member Function Documentation
◆ checkThreadFunc()
| void MyInfo::checkThreadFunc | ( | robot_interaction::LockedRobotState * | locked_state, |
| int * | counter ) |
Definition at line 371 of file locked_robot_state_test.cpp.
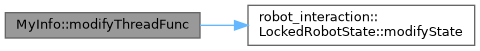
◆ modifyThreadFunc()
| void MyInfo::modifyThreadFunc | ( | robot_interaction::LockedRobotState * | locked_state, |
| int * | counter, | ||
| double | offset ) |
Definition at line 427 of file locked_robot_state_test.cpp.
Here is the call graph for this function:
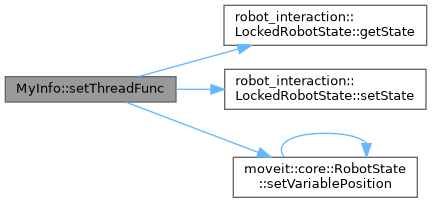
◆ setThreadFunc()
| void MyInfo::setThreadFunc | ( | robot_interaction::LockedRobotState * | locked_state, |
| int * | counter, | ||
| double | offset ) |
Definition at line 389 of file locked_robot_state_test.cpp.
Here is the call graph for this function:
◆ waitThreadFunc()
| void MyInfo::waitThreadFunc | ( | robot_interaction::LockedRobotState * | locked_state, |
| int ** | counters, | ||
| int | max ) |
Definition at line 452 of file locked_robot_state_test.cpp.
The documentation for this class was generated from the following file:
- moveit_ros/robot_interaction/test/locked_robot_state_test.cpp
Generated by
 1.15.0