moveit2
The MoveIt Motion Planning Framework for ROS 2.
Loading...
Searching...
No Matches
TestStateValidityChecker Class Reference

Generic implementation of the tests that can be executed on different robots. More...

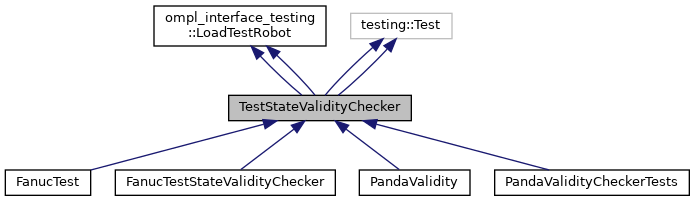
Inheritance diagram for TestStateValidityChecker:
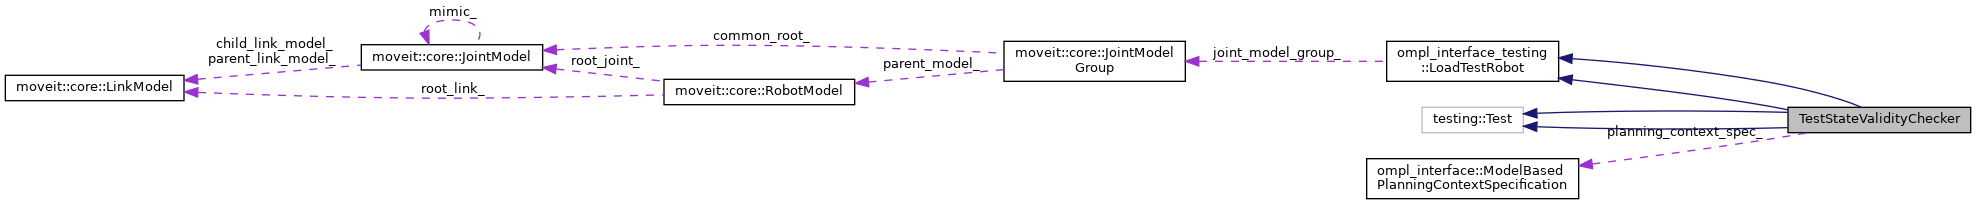
Collaboration diagram for TestStateValidityChecker:

Public Member Functions

 TestStateValidityChecker (const std::string &robot_name, const std::string &group_name)
void testConstructor ()
void testJointLimits (const std::vector< double > &position_in_limits)
void testSelfCollision (const std::vector< double > &position_in_self_collision)
 TestStateValidityChecker (const std::string &robot_name, const std::string &group_name)
void testConstructor ()
void testJointLimits (const std::vector< double > &position_in_limits)
void testSelfCollision (const std::vector< double > &position_in_self_collision)
void testPathConstraints (const std::vector< double > &position_in_joint_limits)

Protected Member Functions

void SetUp () override
void TearDown () override
void setupStateSpace ()
void setupPlanningContext ()
void SetUp () override
void setupStateSpace ()
void setupPlanningContext ()
moveit_msgs::msg::PositionConstraint createPositionConstraint (std::array< double, 3 > position, std::array< double, 3 > dimensions)
 Helper function to create a position constraint.
Protected Member Functions inherited from ompl_interface_testing::LoadTestRobot
 LoadTestRobot (const std::string &robot_name, const std::string &group_name)
Eigen::VectorXd getRandomState () const
Eigen::VectorXd getDeterministicState () const
 Create a joint position vector with values 0.1, 0.2, 0.3, ... where the length depends on the number of joints in the robot.

Protected Attributes

moveit::core::RobotStatePtr initial_robot_state_
ompl_interface::ModelBasedStateSpacePtr state_space_
ompl_interface::ModelBasedPlanningContextSpecification planning_context_spec_
ompl_interface::ModelBasedPlanningContextPtr planning_context_
planning_scene::PlanningScenePtr planning_scene_
ompl::base::ConstrainedStateSpacePtr constrained_state_space_
Protected Attributes inherited from ompl_interface_testing::LoadTestRobot
std::string group_name_
std::string robot_name_
moveit::core::RobotModelPtr robot_model_
moveit::core::RobotStatePtr robot_state_
const moveit::core::JointModelGroupjoint_model_group_
std::size_t num_dofs_
std::string base_link_name_
std::string ee_link_name_

Detailed Description

Generic implementation of the tests that can be executed on different robots.

Definition at line 88 of file test_constrained_state_validity_checker.cpp.

Constructor & Destructor Documentation

◆ TestStateValidityChecker() [1/2]

TestStateValidityChecker::TestStateValidityChecker ( const std::string & robot_name,
const std::string & group_name )
inline

Definition at line 91 of file test_constrained_state_validity_checker.cpp.

Here is the call graph for this function:
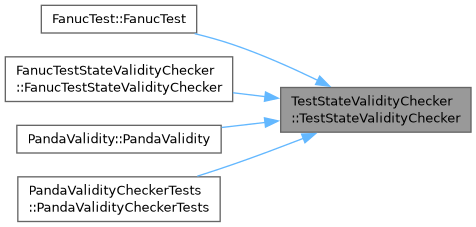
Here is the caller graph for this function:

◆ TestStateValidityChecker() [2/2]

TestStateValidityChecker::TestStateValidityChecker ( const std::string & robot_name,
const std::string & group_name )
inline

Definition at line 88 of file test_state_validity_checker.cpp.

Here is the call graph for this function:

Member Function Documentation

◆ createPositionConstraint()

moveit_msgs::msg::PositionConstraint TestStateValidityChecker::createPositionConstraint ( std::array< double, 3 > position,
std::array< double, 3 > dimensions )
inlineprotected

Helper function to create a position constraint.

Definition at line 231 of file test_state_validity_checker.cpp.

Here is the caller graph for this function:

◆ SetUp() [1/2]

void TestStateValidityChecker::SetUp ( )
inlineoverrideprotected

Definition at line 200 of file test_constrained_state_validity_checker.cpp.

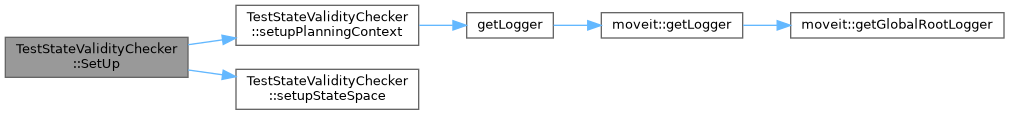
Here is the call graph for this function:

◆ SetUp() [2/2]

void TestStateValidityChecker::SetUp ( )
inlineoverrideprotected

Definition at line 200 of file test_state_validity_checker.cpp.

Here is the call graph for this function:

◆ setupPlanningContext() [1/2]

void TestStateValidityChecker::setupPlanningContext ( )
inlineprotected

Definition at line 222 of file test_constrained_state_validity_checker.cpp.

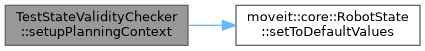
Here is the call graph for this function:
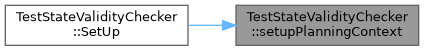
Here is the caller graph for this function:

◆ setupPlanningContext() [2/2]

void TestStateValidityChecker::setupPlanningContext ( )
inlineprotected

Definition at line 214 of file test_state_validity_checker.cpp.

Here is the call graph for this function:

◆ setupStateSpace() [1/2]

void TestStateValidityChecker::setupStateSpace ( )
inlineprotected

Definition at line 211 of file test_constrained_state_validity_checker.cpp.

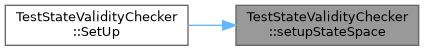
Here is the caller graph for this function:

◆ setupStateSpace() [2/2]

void TestStateValidityChecker::setupStateSpace ( )
inlineprotected

Definition at line 207 of file test_state_validity_checker.cpp.

◆ TearDown()

void TestStateValidityChecker::TearDown ( )
inlineoverrideprotected

Definition at line 207 of file test_constrained_state_validity_checker.cpp.

◆ testConstructor() [1/2]

void TestStateValidityChecker::testConstructor ( )
inline

Definition at line 98 of file test_constrained_state_validity_checker.cpp.

◆ testConstructor() [2/2]

void TestStateValidityChecker::testConstructor ( )
inline

Definition at line 93 of file test_state_validity_checker.cpp.

◆ testJointLimits() [1/2]

void TestStateValidityChecker::testJointLimits ( const std::vector< double > & position_in_limits)
inline

Definition at line 104 of file test_constrained_state_validity_checker.cpp.

Here is the call graph for this function:

◆ testJointLimits() [2/2]

void TestStateValidityChecker::testJointLimits ( const std::vector< double > & position_in_limits)
inline

This test takes a state that is inside the joint limits and collision free as input.

Definition at line 100 of file test_state_validity_checker.cpp.

Here is the call graph for this function:

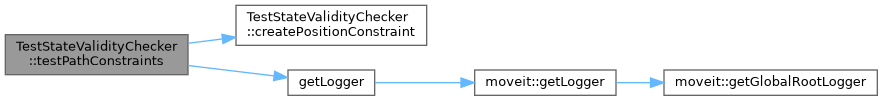
◆ testPathConstraints()

void TestStateValidityChecker::testPathConstraints ( const std::vector< double > & position_in_joint_limits)
inline

Definition at line 155 of file test_state_validity_checker.cpp.

Here is the call graph for this function:

◆ testSelfCollision() [1/2]

void TestStateValidityChecker::testSelfCollision ( const std::vector< double > & position_in_self_collision)
inline

Definition at line 156 of file test_constrained_state_validity_checker.cpp.

Here is the call graph for this function:

◆ testSelfCollision() [2/2]

void TestStateValidityChecker::testSelfCollision ( const std::vector< double > & position_in_self_collision)
inline

This test takes a state that is known to be in self-collision and inside the joint limits as input.

Definition at line 131 of file test_state_validity_checker.cpp.

Here is the call graph for this function:

Member Data Documentation

◆ constrained_state_space_

ompl::base::ConstrainedStateSpacePtr TestStateValidityChecker::constrained_state_space_
protected

Definition at line 255 of file test_constrained_state_validity_checker.cpp.

◆ initial_robot_state_

moveit::core::RobotStatePtr TestStateValidityChecker::initial_robot_state_
protected

Definition at line 248 of file test_constrained_state_validity_checker.cpp.

◆ planning_context_

ompl_interface::ModelBasedPlanningContextPtr TestStateValidityChecker::planning_context_
protected

Definition at line 252 of file test_constrained_state_validity_checker.cpp.

◆ planning_context_spec_

ompl_interface::ModelBasedPlanningContextSpecification TestStateValidityChecker::planning_context_spec_
protected

Definition at line 251 of file test_constrained_state_validity_checker.cpp.

◆ planning_scene_

planning_scene::PlanningScenePtr TestStateValidityChecker::planning_scene_
protected

Definition at line 253 of file test_constrained_state_validity_checker.cpp.

◆ state_space_

ompl_interface::ModelBasedStateSpacePtr TestStateValidityChecker::state_space_
protected

Definition at line 250 of file test_constrained_state_validity_checker.cpp.


The documentation for this class was generated from the following files: