moveit_rviz_plugin::PlanningSceneRender Class Reference
#include <planning_scene_render.hpp>
Public Member Functions | |
| PlanningSceneRender (Ogre::SceneNode *root_node, rviz_common::DisplayContext *context, const RobotStateVisualizationPtr &robot) | |
| ~PlanningSceneRender () | |
| Ogre::SceneNode * | getGeometryNode () |
| const RobotStateVisualizationPtr & | getRobotVisualization () |
| void | updateRobotPosition (const planning_scene::PlanningSceneConstPtr &scene) |
| void | renderPlanningScene (const planning_scene::PlanningSceneConstPtr &scene, const Ogre::ColourValue &default_scene_color, const Ogre::ColourValue &default_attached_color, OctreeVoxelRenderMode voxel_render_mode, OctreeVoxelColorMode voxel_color_mode, double default_scene_alpha) |
| void | clear () |
Detailed Description
Definition at line 51 of file planning_scene_render.hpp.
Constructor & Destructor Documentation
◆ PlanningSceneRender()
| moveit_rviz_plugin::PlanningSceneRender::PlanningSceneRender | ( | Ogre::SceneNode * | root_node, |
| rviz_common::DisplayContext * | context, | ||
| const RobotStateVisualizationPtr & | robot ) |
Definition at line 47 of file planning_scene_render.cpp.
◆ ~PlanningSceneRender()
| moveit_rviz_plugin::PlanningSceneRender::~PlanningSceneRender | ( | ) |
Definition at line 54 of file planning_scene_render.cpp.
Member Function Documentation
◆ clear()
| void moveit_rviz_plugin::PlanningSceneRender::clear | ( | ) |
Definition at line 69 of file planning_scene_render.cpp.
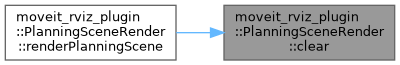
Here is the caller graph for this function:
◆ getGeometryNode()
|
inline |
Definition at line 58 of file planning_scene_render.hpp.
◆ getRobotVisualization()
|
inline |
Definition at line 63 of file planning_scene_render.hpp.
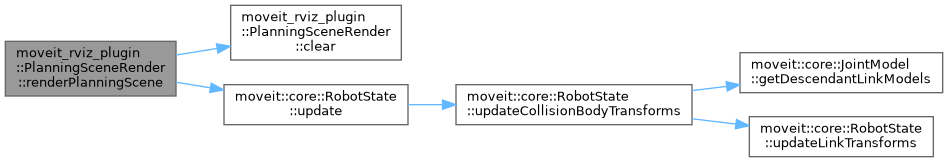
◆ renderPlanningScene()
| void moveit_rviz_plugin::PlanningSceneRender::renderPlanningScene | ( | const planning_scene::PlanningSceneConstPtr & | scene, |
| const Ogre::ColourValue & | default_scene_color, | ||
| const Ogre::ColourValue & | default_attached_color, | ||
| OctreeVoxelRenderMode | voxel_render_mode, | ||
| OctreeVoxelColorMode | voxel_color_mode, | ||
| double | default_scene_alpha ) |
◆ updateRobotPosition()
| void moveit_rviz_plugin::PlanningSceneRender::updateRobotPosition | ( | const planning_scene::PlanningSceneConstPtr & | scene | ) |
Definition at line 59 of file planning_scene_render.cpp.
The documentation for this class was generated from the following files:
- moveit_ros/visualization/rviz_plugin_render_tools/include/moveit/rviz_plugin_render_tools/planning_scene_render.hpp
- moveit_ros/visualization/rviz_plugin_render_tools/src/planning_scene_render.cpp
Generated by
 1.15.0