ompl_interface::ConstrainedGoalSampler Class Reference
#include <constrained_goal_sampler.hpp>
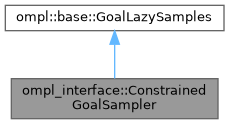
Inheritance diagram for ompl_interface::ConstrainedGoalSampler:
Collaboration diagram for ompl_interface::ConstrainedGoalSampler:
Public Member Functions | |
| ConstrainedGoalSampler (const ModelBasedPlanningContext *pc, kinematic_constraints::KinematicConstraintSetPtr ks, constraint_samplers::ConstraintSamplerPtr cs=constraint_samplers::ConstraintSamplerPtr()) | |
Detailed Description
An interface to the OMPL goal lazy sampler
Definition at line 52 of file constrained_goal_sampler.hpp.
Constructor & Destructor Documentation
◆ ConstrainedGoalSampler()
| ompl_interface::ConstrainedGoalSampler::ConstrainedGoalSampler | ( | const ModelBasedPlanningContext * | pc, |
| kinematic_constraints::KinematicConstraintSetPtr | ks, | ||
| constraint_samplers::ConstraintSamplerPtr | cs = constraint_samplers::ConstraintSamplerPtr() ) |
Definition at line 54 of file constrained_goal_sampler.cpp.
The documentation for this class was generated from the following files:
- moveit_planners/ompl/ompl_interface/include/moveit/ompl_interface/detail/constrained_goal_sampler.hpp
- moveit_planners/ompl/ompl_interface/src/detail/constrained_goal_sampler.cpp
Generated by
 1.15.0