#include <acceleration_filter.hpp>
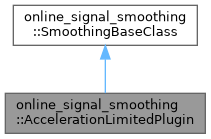
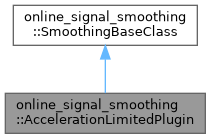
Public Member Functions | |
| bool | initialize (rclcpp::Node::SharedPtr node, moveit::core::RobotModelConstPtr robot_model, size_t num_joints) override |
| bool | doSmoothing (Eigen::VectorXd &positions, Eigen::VectorXd &velocities, Eigen::VectorXd &accelerations) override |
| bool | reset (const Eigen::VectorXd &positions, const Eigen::VectorXd &velocities, const Eigen::VectorXd &accelerations) override |
| ~AccelerationLimitedPlugin () override | |
| Public Member Functions inherited from online_signal_smoothing::SmoothingBaseClass | |
| SmoothingBaseClass () | |
| virtual | ~SmoothingBaseClass () |
Detailed Description
Definition at line 121 of file acceleration_filter.hpp.
Constructor & Destructor Documentation
◆ ~AccelerationLimitedPlugin()
|
inlineoverride |
memory allocated by osqp is freed in destructor
Definition at line 157 of file acceleration_filter.hpp.
Member Function Documentation
◆ doSmoothing()
|
overridevirtual |
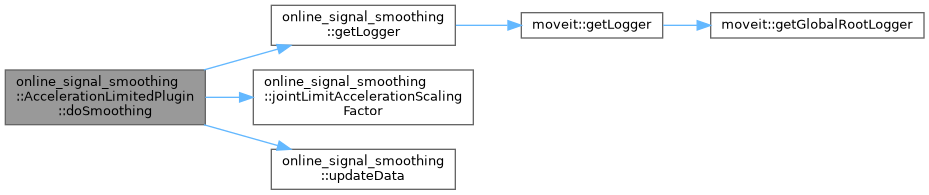
Smooth the command signals for all DOF. This function limits the change in velocity using the acceleration specified in the robot model.
- Parameters
-
positions array of joint position commands velocities array of joint velocity commands accelerations (unused)
- Returns
- True if smoothing was successful
Implements online_signal_smoothing::SmoothingBaseClass.
Definition at line 309 of file acceleration_filter.cpp.
◆ initialize()
|
overridevirtual |
Initialize the acceleration based smoothing plugin
- Parameters
-
node ROS node, used for parameter retrieval robot_model typically used to retrieve vel/accel/jerk limits num_joints number of actuated joints in the JointGroup Servo controls
- Returns
- True if initialization was successful
Implements online_signal_smoothing::SmoothingBaseClass.
Definition at line 171 of file acceleration_filter.cpp.

◆ reset()
|
overridevirtual |
Reset to a given joint state. This method must be called before doSmoothing.
- Parameters
-
positions reset the filters to the joint positions velocities reset the filters to the joint velocities accelerations (unused)
- Returns
- True if reset was successful
Implements online_signal_smoothing::SmoothingBaseClass.
Definition at line 397 of file acceleration_filter.cpp.
The documentation for this class was generated from the following files:
- moveit_core/online_signal_smoothing/include/moveit/online_signal_smoothing/acceleration_filter.hpp
- moveit_core/online_signal_smoothing/src/acceleration_filter.cpp
Generated by
 1.15.0