#include <constrained_planning_state_space_factory.hpp>
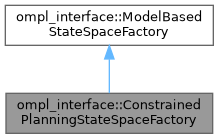
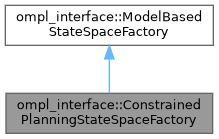
Public Member Functions | |
| ConstrainedPlanningStateSpaceFactory () | |
| int | canRepresentProblem (const std::string &group, const moveit_msgs::msg::MotionPlanRequest &req, const moveit::core::RobotModelConstPtr &robot_model) const override |
| Return a priority that this planner should be used for this specific planning problem. | |
| Public Member Functions inherited from ompl_interface::ModelBasedStateSpaceFactory | |
| ModelBasedStateSpaceFactory () | |
| virtual | ~ModelBasedStateSpaceFactory () |
| ModelBasedStateSpacePtr | getNewStateSpace (const ModelBasedStateSpaceSpecification &space_spec) const |
| const std::string & | getType () const |
Protected Member Functions | |
| ModelBasedStateSpacePtr | allocStateSpace (const ModelBasedStateSpaceSpecification &space_spec) const override |
Additional Inherited Members | |
| Protected Attributes inherited from ompl_interface::ModelBasedStateSpaceFactory | |
| std::string | type_ |
Detailed Description
Definition at line 44 of file constrained_planning_state_space_factory.hpp.
Constructor & Destructor Documentation
◆ ConstrainedPlanningStateSpaceFactory()
| ompl_interface::ConstrainedPlanningStateSpaceFactory::ConstrainedPlanningStateSpaceFactory | ( | ) |
Definition at line 43 of file constrained_planning_state_space_factory.cpp.
Member Function Documentation
◆ allocStateSpace()
|
overrideprotectedvirtual |
Implements ompl_interface::ModelBasedStateSpaceFactory.
Definition at line 66 of file constrained_planning_state_space_factory.cpp.
◆ canRepresentProblem()
|
overridevirtual |
Return a priority that this planner should be used for this specific planning problem.
This state space factory is currently only used if there is exactly one position or orientation constraint, or if enforce_constrained_state_space was set to true in ompl_planning.yaml. In the first case, we prefer planning in the constrained state space and return a priority of 200. In the second case, it is the only factory to choose from, so the priority does not matter, and it returns a low priority so it will never be chosen when others are available. (The second lowest priority is -1 in the PoseModelStateSpaceFactory.)
For more details on this state space selection process, see: https://github.com/JeroenDM/moveit/pull/2
Implements ompl_interface::ModelBasedStateSpaceFactory.
Definition at line 48 of file constrained_planning_state_space_factory.cpp.
The documentation for this class was generated from the following files:
- moveit_planners/ompl/ompl_interface/include/moveit/ompl_interface/parameterization/joint_space/constrained_planning_state_space_factory.hpp
- moveit_planners/ompl/ompl_interface/src/parameterization/joint_space/constrained_planning_state_space_factory.cpp
Generated by
 1.15.0