#include <rclcpp/executors/single_threaded_executor.hpp>#include <rclcpp/rclcpp.hpp>#include <moveit/robot_state/conversions.hpp>#include <moveit/robot_state/robot_state.hpp>#include <moveit/trajectory_cache/trajectory_cache.hpp>#include <moveit/trajectory_cache/utils/utils.hpp>#include <atomic>#include <thread>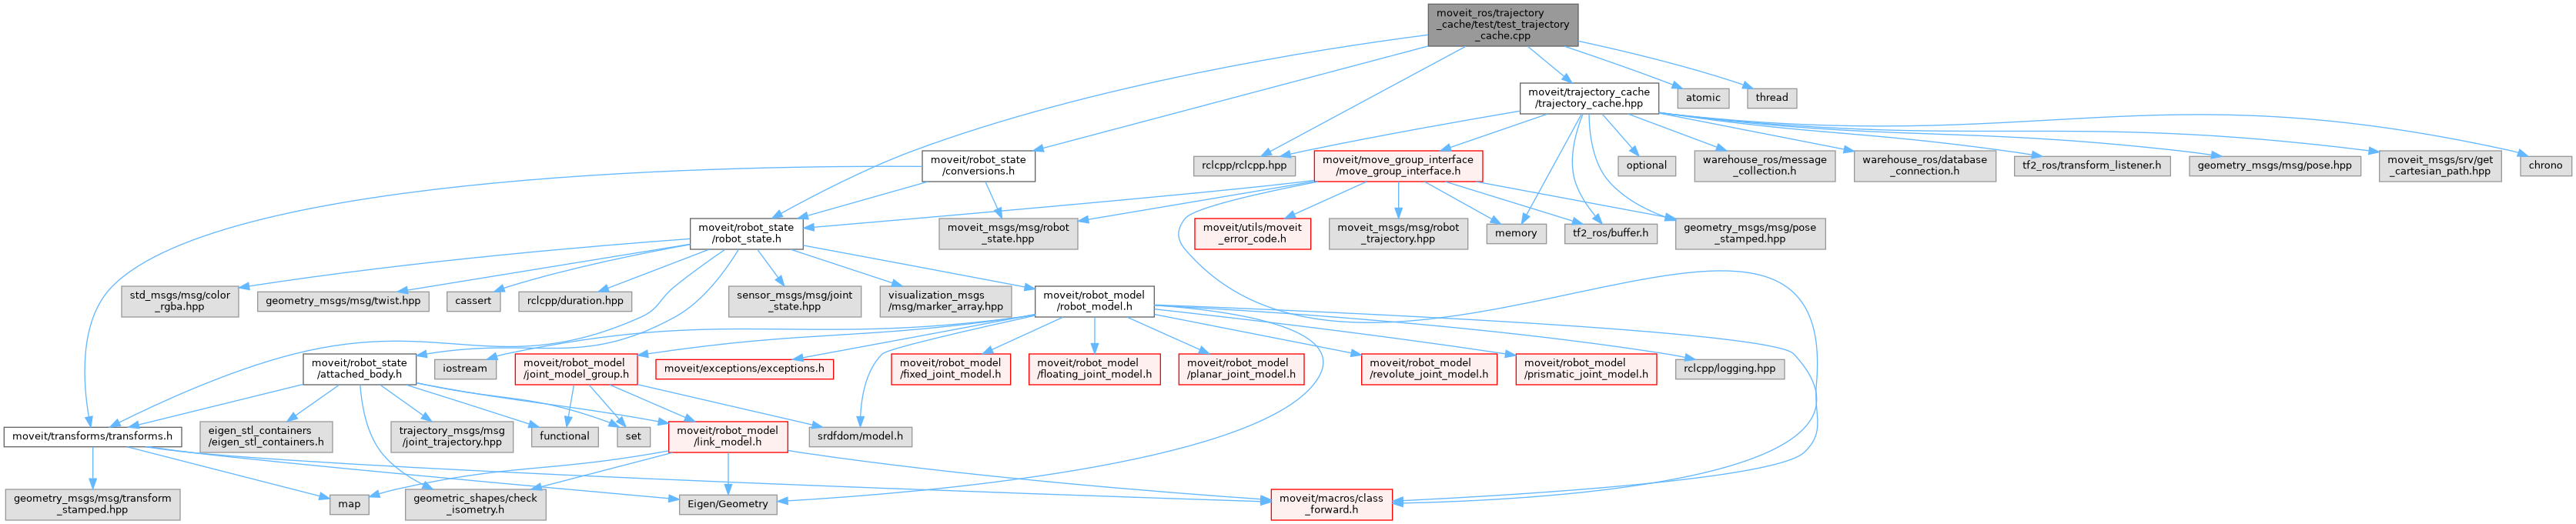
Go to the source code of this file.
Classes | |
| class | MoveGroupInterface |
| Client class to conveniently use the ROS interfaces provided by the move_group node. More... | |
| class | TrajectoryCache |
| Trajectory Cache manager for MoveIt. More... | |
Functions | |
| void | checkAndEmit (bool predicate, const std::string &test_case, const std::string &label) |
| moveit_msgs::msg::RobotTrajectory | getDummyPandaTraj () |
| std::vector< geometry_msgs::msg::Pose > | getDummyWaypoints () |
| void | testGettersAndSetters (const std::shared_ptr< TrajectoryCache > &cache) |
| void | testMotionTrajectories (const std::shared_ptr< MoveGroupInterface > &move_group, const std::shared_ptr< TrajectoryCache > &cache) |
| void | testCartesianTrajectories (const std::shared_ptr< MoveGroupInterface > &move_group, const std::shared_ptr< TrajectoryCache > &cache) |
| int | main (int argc, char **argv) |
| moveit_msgs::srv::GetCartesianPath::Request | constructGetCartesianPathRequest (moveit::planning_interface::MoveGroupInterface &move_group, const std::vector< geometry_msgs::msg::Pose > &waypoints, double max_step, double jump_threshold, bool avoid_collisions=true) |
| Constructs a GetCartesianPath request. | |
Variables | |
| const std::string | ROBOT_NAME = "panda" |
| const std::string | ROBOT_FRAME = "world" |
Detailed Description
Definition in file test_trajectory_cache.cpp.
Function Documentation
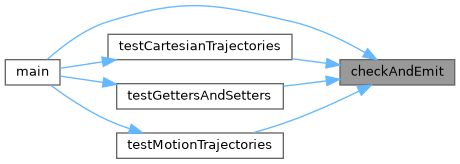
◆ checkAndEmit()
| void checkAndEmit | ( | bool | predicate, |
| const std::string & | test_case, | ||
| const std::string & | label ) |
Definition at line 39 of file test_trajectory_cache.cpp.
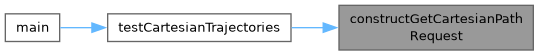
◆ constructGetCartesianPathRequest()
| GetCartesianPath::Request moveit_ros::trajectory_cache::constructGetCartesianPathRequest | ( | moveit::planning_interface::MoveGroupInterface & | move_group, |
| const std::vector< geometry_msgs::msg::Pose > & | waypoints, | ||
| double | max_step, | ||
| double | jump_threshold, | ||
| bool | avoid_collisions = true ) |
Constructs a GetCartesianPath request.
This is a convenience function. This mimics the move group computeCartesianPath signature (without path constraints).
WARNING: The following fields are not supported, if you want to specify them, add them in yourself.
- prismatic_jump_threshold
- revolute_jump_threshold
- cartesian_speed_limited_link
- max_cartesian_speed
- Parameters
-
[in] move_group. The manipulator move group, used to get its state, frames, and link. [in] waypoints. The cartesian waypoints to request the path for. [in] max_step. The value to populate into the GetCartesianPath request's max_step field. [in] jump_threshold. The value to populate into the GetCartesianPath request's jump_threshold field. [in] avoid_collisions. The value to populate into the GetCartesianPath request's avoid_collisions field.
- Returns
Definition at line 161 of file utils.cpp.
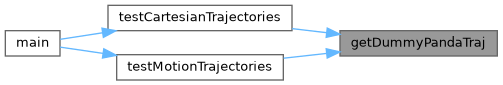
◆ getDummyPandaTraj()
| moveit_msgs::msg::RobotTrajectory getDummyPandaTraj | ( | ) |
Definition at line 51 of file test_trajectory_cache.cpp.
◆ getDummyWaypoints()
| std::vector< geometry_msgs::msg::Pose > getDummyWaypoints | ( | ) |
Definition at line 78 of file test_trajectory_cache.cpp.

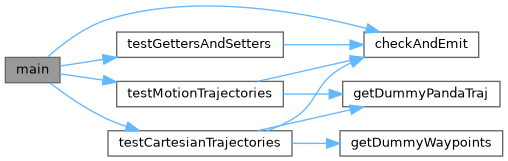
◆ main()
| int main | ( | int | argc, |
| char ** | argv ) |
Definition at line 1029 of file test_trajectory_cache.cpp.
◆ testCartesianTrajectories()
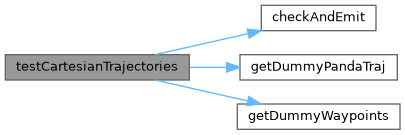
| void testCartesianTrajectories | ( | const std::shared_ptr< MoveGroupInterface > & | move_group, |
| const std::shared_ptr< TrajectoryCache > & | cache ) |
First, test if construction even works...
GetCartesianPath::Request
RobotTrajectory
Definition at line 577 of file test_trajectory_cache.cpp.
◆ testGettersAndSetters()
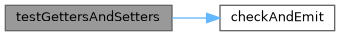
| void testGettersAndSetters | ( | const std::shared_ptr< TrajectoryCache > & | cache | ) |
Definition at line 98 of file test_trajectory_cache.cpp.
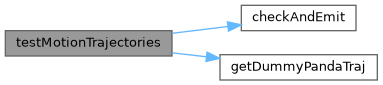
◆ testMotionTrajectories()
| void testMotionTrajectories | ( | const std::shared_ptr< MoveGroupInterface > & | move_group, |
| const std::shared_ptr< TrajectoryCache > & | cache ) |
MotionPlanRequest
RobotTrajectory
Definition at line 116 of file test_trajectory_cache.cpp.
Variable Documentation
◆ ROBOT_FRAME
| const std::string ROBOT_FRAME = "world" |
Definition at line 35 of file test_trajectory_cache.cpp.
◆ ROBOT_NAME
| const std::string ROBOT_NAME = "panda" |
Definition at line 34 of file test_trajectory_cache.cpp.
Generated by
 1.15.0