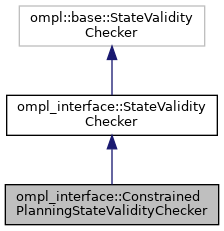
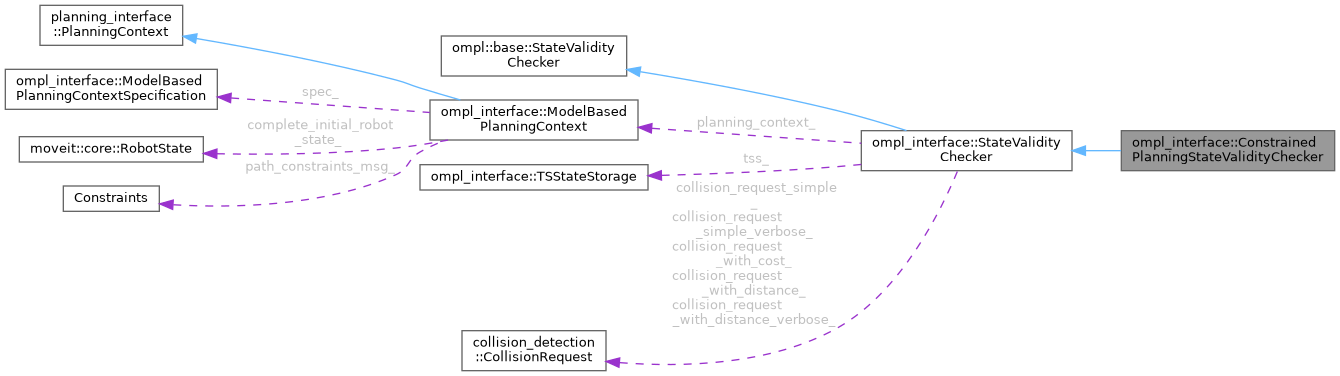
A StateValidityChecker that can handle states of type ompl::base::ConstraintStateSpace::StateType. More...
#include <state_validity_checker.hpp>
Public Member Functions | |
| ConstrainedPlanningStateValidityChecker (const ModelBasedPlanningContext *planning_context) | |
| bool | isValid (const ompl::base::State *wrapped_state, bool verbose) const override |
| Check validity for states of type ompl::base::ConstrainedStateSpace. | |
| bool | isValid (const ompl::base::State *wrapped_state, double &dist, bool verbose) const override |
| bool | isValid (const ompl::base::State *state) const override |
| bool | isValid (const ompl::base::State *state, double &dist) const override |
| bool | isValid (const ompl::base::State *state, double &dist, ompl::base::State *, bool &) const override |
| Public Member Functions inherited from ompl_interface::StateValidityChecker | |
| StateValidityChecker (const ModelBasedPlanningContext *planning_context) | |
| bool | isValid (const ompl::base::State *state) const override |
| bool | isValid (const ompl::base::State *state, double &dist) const override |
| bool | isValid (const ompl::base::State *state, double &dist, ompl::base::State *, bool &) const override |
| virtual double | cost (const ompl::base::State *state) const |
| double | clearance (const ompl::base::State *state) const override |
| void | setVerbose (bool flag) |
Detailed Description
A StateValidityChecker that can handle states of type ompl::base::ConstraintStateSpace::StateType.
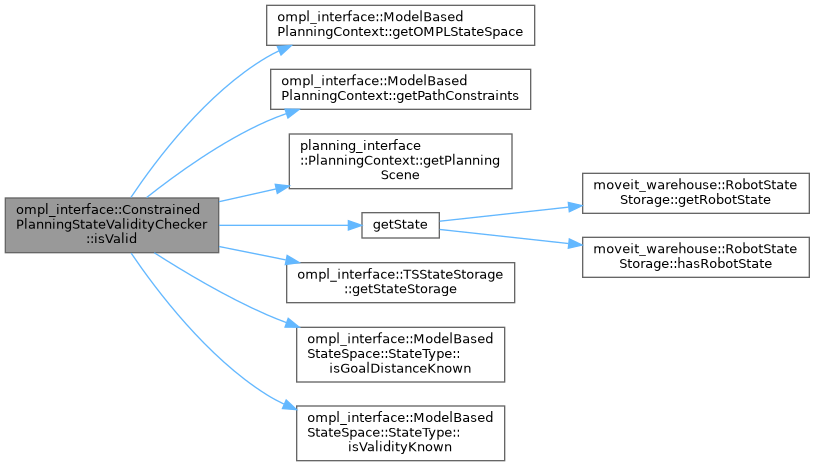
We cannot not just cast the states and pass them to the isValid version of the parent class, because inside the state-validity checker, the line:
planning_context_->getOMPLStateSpace()->copyToRobotState(*robot_state, state);
requires the state type to be of the constrained state space, while:
state->as<ModelBasedStateSpace::StateType>()->isValidityKnown()
requires accessing the underlying state by calling getState() on the constrained state space state. Therefore this class implements specific versions of the isValid methods.
We still check the path constraints, because not all states sampled by the constrained state space satisfy the constraints unfortunately. This is a complicated issue. For more details see: https://github.com/moveit/moveit/issues/2092#issuecomment-669911722.
Definition at line 120 of file state_validity_checker.hpp.
Constructor & Destructor Documentation
◆ ConstrainedPlanningStateValidityChecker()
|
inline |
Definition at line 126 of file state_validity_checker.hpp.
Member Function Documentation
◆ isValid() [1/5]
|
inlineoverride |
Definition at line 65 of file state_validity_checker.hpp.
◆ isValid() [2/5]
|
inlineoverride |
Definition at line 70 of file state_validity_checker.hpp.
◆ isValid() [3/5]
|
inlineoverride |
Definition at line 75 of file state_validity_checker.hpp.
◆ isValid() [4/5]
|
overridevirtual |
Check validity for states of type ompl::base::ConstrainedStateSpace.
This state type is special in that it "wraps" around a normal state, which can be accessed by the getState() method. In this class we assume that this state, is of type ompl_interface::ConstrainedPlanningStateSpace, which inherits from ompl_interface::ModelBasedStateSpace.
(For the actual implementation of this, look at the ompl::base::WrapperStateSpace.)
Code sample that can be used to check all the assumptions:
#include <moveit/ompl_interface/parameterization/joint_space/constrained_planning_state_space.hpp> #include <ompl/base/ConstrainedSpaceInformation.h>
// the code below should be pasted at the top of the isValid method auto css = dynamic_cast<const ompl::base::ConstrainedStateSpace::StateType*>(wrapped_state); assert(css != nullptr); auto cpss = dynamic_cast<const ConstrainedPlanningStateSpace*>(planning_context_->getOMPLStateSpace().get()); assert(cpss != nullptr); auto cssi = dynamic_cast<const ompl::base::ConstrainedSpaceInformation*>(si_); assert(cssi != nullptr);
Reimplemented from ompl_interface::StateValidityChecker.
Definition at line 221 of file state_validity_checker.cpp.

◆ isValid() [5/5]
|
overridevirtual |
Reimplemented from ompl_interface::StateValidityChecker.
Definition at line 275 of file state_validity_checker.cpp.
The documentation for this class was generated from the following files:
- moveit_planners/ompl/ompl_interface/include/moveit/ompl_interface/detail/state_validity_checker.hpp
- moveit_planners/ompl/ompl_interface/src/detail/state_validity_checker.cpp
Generated by
 1.15.0