#include <moveit/planning_scene_monitor/planning_scene_monitor.hpp>#include <moveit/collision_plugin_loader/collision_plugin_loader.hpp>#include <moveit/collision_detection_bullet/collision_detector_allocator_bullet.hpp>#include <moveit/collision_detection_fcl/collision_detector_allocator_fcl.hpp>#include <geometric_shapes/shape_operations.h>#include <random_numbers/random_numbers.h>#include <moveit/robot_model/robot_model.hpp>#include <moveit/utils/robot_model_test_utils.hpp>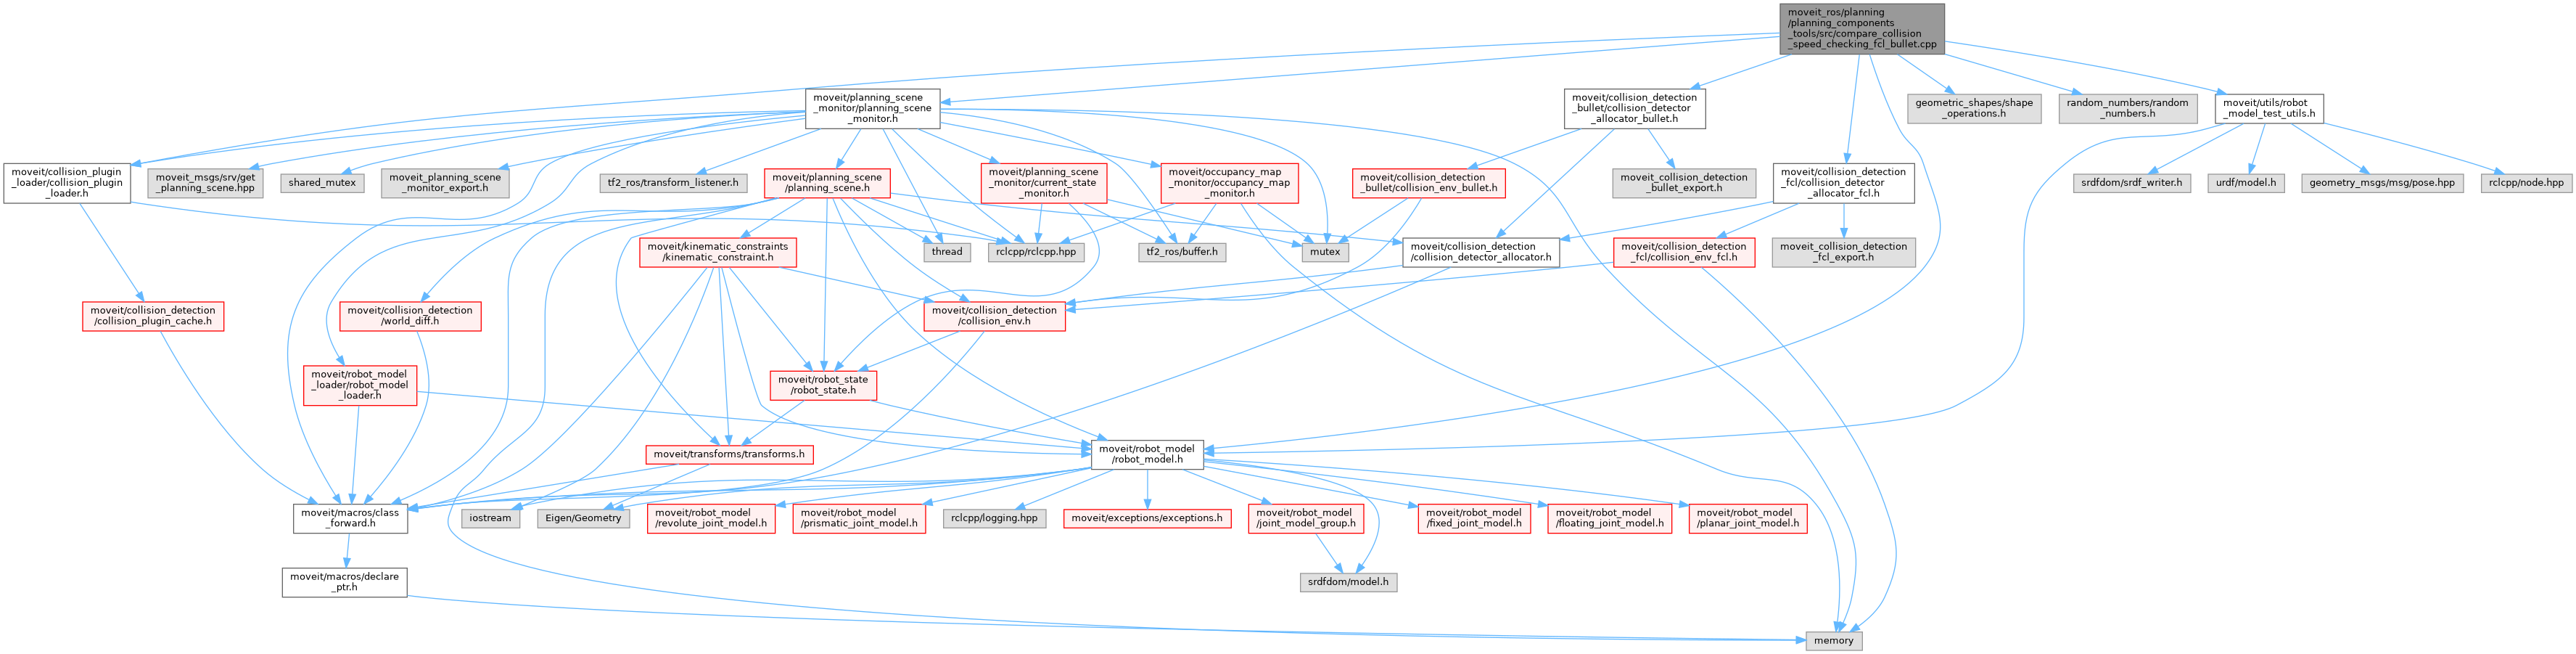
Go to the source code of this file.
Enumerations | |
| enum class | RobotStateSelector { IN_COLLISION , NOT_IN_COLLISION , RANDOM } |
| Defines a random robot state. More... | |
| enum class | CollisionDetector { FCL , BULLET } |
| Enumerates the available collision detectors. More... | |
| enum class | CollisionObjectType { MESH , BOX } |
| Enumerates the different types of collision objects. More... | |
Functions | |
| void | clutterWorld (const planning_scene::PlanningScenePtr &planning_scene, const size_t num_objects, CollisionObjectType type) |
| Clutters the world of the planning scene with random objects in a certain area around the origin. All added objects are not in collision with the robot. | |
| void | runCollisionDetection (unsigned int trials, const planning_scene::PlanningScenePtr &scene, const std::vector< moveit::core::RobotState > &states, const CollisionDetector col_detector, bool only_self, bool distance=false) |
| Runs a collision detection benchmark and measures the time. | |
| void | findStates (const RobotStateSelector desired_states, unsigned int num_states, const planning_scene::PlanningScenePtr &scene, std::vector< moveit::core::RobotState > &robot_states) |
| Samples valid states of the robot which can be in collision if desired. | |
| int | main (int argc, char **argv) |
Enumeration Type Documentation
◆ CollisionDetector
|
strong |
Enumerates the available collision detectors.
| Enumerator | |
|---|---|
| FCL | |
| BULLET | |
Definition at line 64 of file compare_collision_speed_checking_fcl_bullet.cpp.
◆ CollisionObjectType
|
strong |
Enumerates the different types of collision objects.
| Enumerator | |
|---|---|
| MESH | |
| BOX | |
Definition at line 71 of file compare_collision_speed_checking_fcl_bullet.cpp.
◆ RobotStateSelector
|
strong |
Defines a random robot state.
| Enumerator | |
|---|---|
| IN_COLLISION | |
| NOT_IN_COLLISION | |
| RANDOM | |
Definition at line 56 of file compare_collision_speed_checking_fcl_bullet.cpp.
Function Documentation
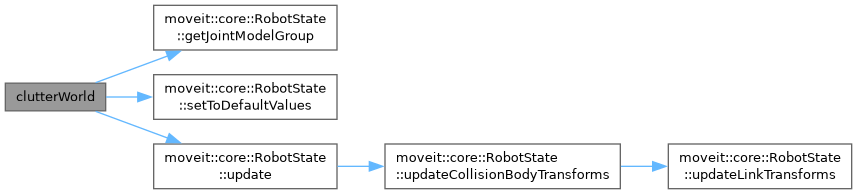
◆ clutterWorld()
| void clutterWorld | ( | const planning_scene::PlanningScenePtr & | planning_scene, |
| const size_t | num_objects, | ||
| CollisionObjectType | type ) |
Clutters the world of the planning scene with random objects in a certain area around the origin. All added objects are not in collision with the robot.
- Parameters
-
planning_scene The planning scene num_objects The number of objects to be cluttered CollisionObjectType Type of object to clutter (mesh or box)
Definition at line 83 of file compare_collision_speed_checking_fcl_bullet.cpp.
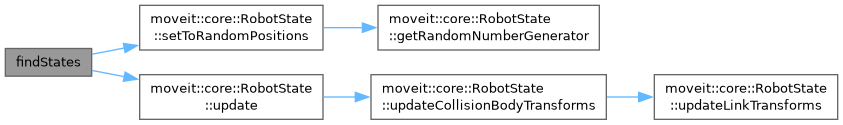
◆ findStates()
| void findStates | ( | const RobotStateSelector | desired_states, |
| unsigned int | num_states, | ||
| const planning_scene::PlanningScenePtr & | scene, | ||
| std::vector< moveit::core::RobotState > & | robot_states ) |
Samples valid states of the robot which can be in collision if desired.
- Parameters
-
desired_states Specifier for type for desired state num_states Number of desired states scene The planning scene robot_states Result vector
Definition at line 250 of file compare_collision_speed_checking_fcl_bullet.cpp.
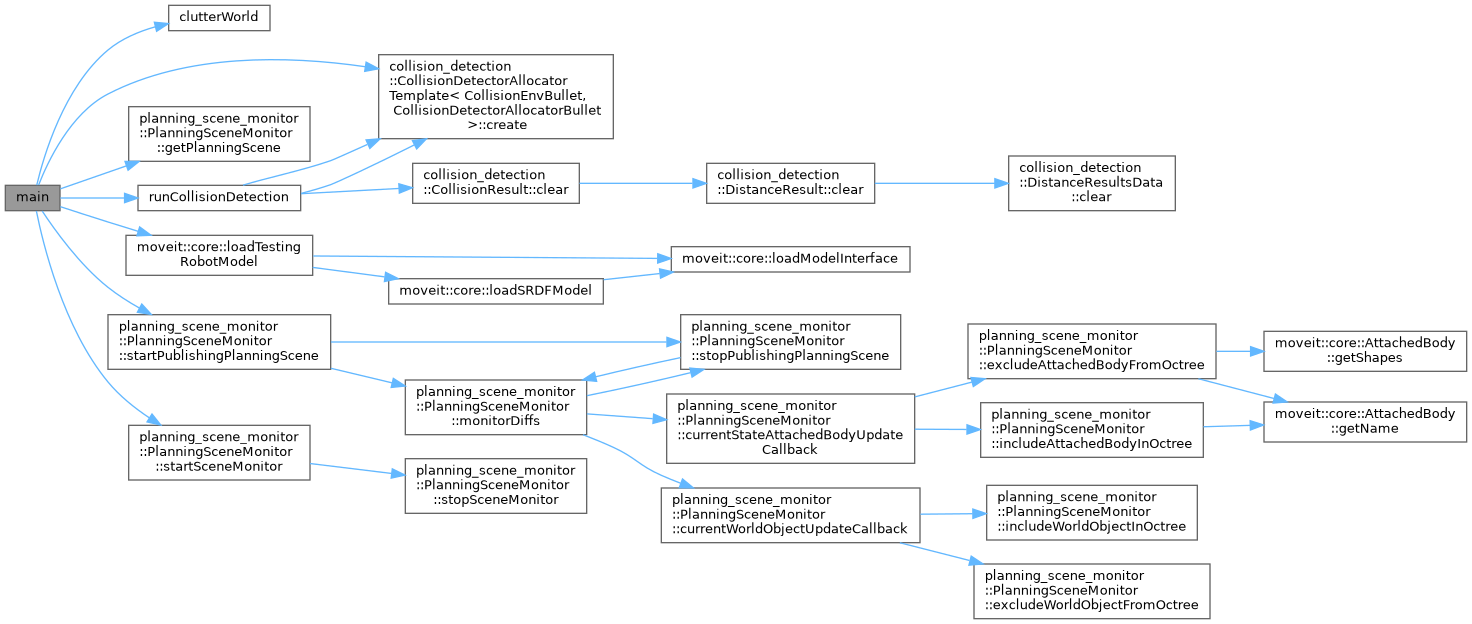
◆ main()
| int main | ( | int | argc, |
| char ** | argv ) |
Definition at line 292 of file compare_collision_speed_checking_fcl_bullet.cpp.
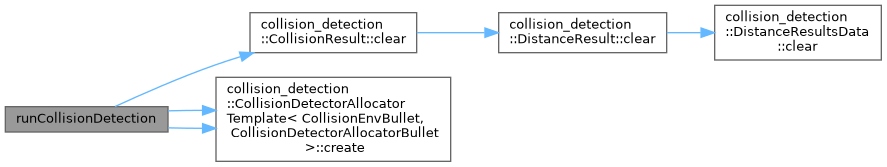
◆ runCollisionDetection()
| void runCollisionDetection | ( | unsigned int | trials, |
| const planning_scene::PlanningScenePtr & | scene, | ||
| const std::vector< moveit::core::RobotState > & | states, | ||
| const CollisionDetector | col_detector, | ||
| bool | only_self, | ||
| bool | distance = false ) |
Runs a collision detection benchmark and measures the time.
- Parameters
-
trials The number of repeated collision checks for each state scene The planning scene CollisionDetector The type of collision detector only_self Flag for only self collision check performed
Definition at line 173 of file compare_collision_speed_checking_fcl_bullet.cpp.
Generated by
 1.15.0