Public Member Functions | |
| MoveGroupInterfaceImpl (const rclcpp::Node::SharedPtr &node, const Options &opt, const std::shared_ptr< tf2_ros::Buffer > &tf_buffer, const rclcpp::Duration &wait_for_servers) | |
| ~MoveGroupInterfaceImpl () | |
| const std::shared_ptr< tf2_ros::Buffer > & | getTF () const |
| const Options & | getOptions () const |
| const moveit::core::RobotModelConstPtr & | getRobotModel () const |
| const moveit::core::JointModelGroup * | getJointModelGroup () const |
| rclcpp_action::Client< moveit_msgs::action::MoveGroup > & | getMoveGroupClient () const |
| bool | getInterfaceDescription (moveit_msgs::msg::PlannerInterfaceDescription &desc) |
| bool | getInterfaceDescriptions (std::vector< moveit_msgs::msg::PlannerInterfaceDescription > &desc) |
| std::map< std::string, std::string > | getPlannerParams (const std::string &planner_id, const std::string &group="") |
| void | setPlannerParams (const std::string &planner_id, const std::string &group, const std::map< std::string, std::string > ¶ms, bool replace=false) |
| std::string | getDefaultPlanningPipelineId () const |
| void | setPlanningPipelineId (const std::string &pipeline_id) |
| const std::string & | getPlanningPipelineId () const |
| std::string | getDefaultPlannerId (const std::string &group) const |
| void | setPlannerId (const std::string &planner_id) |
| const std::string & | getPlannerId () const |
| void | setNumPlanningAttempts (unsigned int num_planning_attempts) |
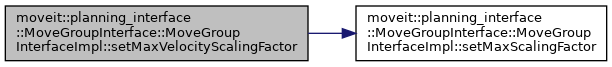
| void | setMaxVelocityScalingFactor (double value) |
| double | getMaxVelocityScalingFactor () const |
| void | setMaxAccelerationScalingFactor (double value) |
| double | getMaxAccelerationScalingFactor () const |
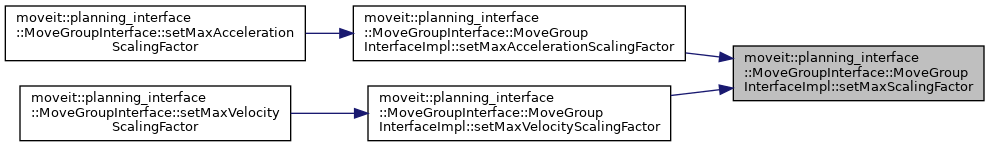
| void | setMaxScalingFactor (double &variable, const double target_value, const char *factor_name, double fallback_value) |
| moveit::core::RobotState & | getTargetRobotState () |
| const moveit::core::RobotState & | getTargetRobotState () const |
| void | setStartState (const moveit_msgs::msg::RobotState &start_state) |
| void | setStartState (const moveit::core::RobotState &start_state) |
| void | setStartStateToCurrentState () |
| moveit::core::RobotStatePtr | getStartState () |
| bool | setJointValueTarget (const geometry_msgs::msg::Pose &eef_pose, const std::string &end_effector_link, const std::string &frame, bool approx) |
| void | setEndEffectorLink (const std::string &end_effector) |
| void | clearPoseTarget (const std::string &end_effector_link) |
| void | clearPoseTargets () |
| const std::string & | getEndEffectorLink () const |
| const std::string & | getEndEffector () const |
| bool | setPoseTargets (const std::vector< geometry_msgs::msg::PoseStamped > &poses, const std::string &end_effector_link) |
| bool | hasPoseTarget (const std::string &end_effector_link) const |
| const geometry_msgs::msg::PoseStamped & | getPoseTarget (const std::string &end_effector_link) const |
| const std::vector< geometry_msgs::msg::PoseStamped > & | getPoseTargets (const std::string &end_effector_link) const |
| void | setPoseReferenceFrame (const std::string &pose_reference_frame) |
| const std::string & | getPoseReferenceFrame () const |
| void | setTargetType (ActiveTargetType type) |
| ActiveTargetType | getTargetType () const |
| bool | startStateMonitor (double wait) |
| bool | getCurrentState (moveit::core::RobotStatePtr ¤t_state, double wait_seconds=1.0) |
| moveit::core::MoveItErrorCode | plan (Plan &plan) |
| moveit::core::MoveItErrorCode | move (bool wait) |
| moveit::core::MoveItErrorCode | execute (const moveit_msgs::msg::RobotTrajectory &trajectory, bool wait, const std::vector< std::string > &controllers=std::vector< std::string >()) |
| double | computeCartesianPath (const std::vector< geometry_msgs::msg::Pose > &waypoints, double step, moveit_msgs::msg::RobotTrajectory &msg, const moveit_msgs::msg::Constraints &path_constraints, bool avoid_collisions, moveit_msgs::msg::MoveItErrorCodes &error_code) |
| void | stop () |
| bool | attachObject (const std::string &object, const std::string &link, const std::vector< std::string > &touch_links) |
| bool | detachObject (const std::string &name) |
| double | getGoalPositionTolerance () const |
| double | getGoalOrientationTolerance () const |
| double | getGoalJointTolerance () const |
| void | setGoalJointTolerance (double tolerance) |
| void | setGoalPositionTolerance (double tolerance) |
| void | setGoalOrientationTolerance (double tolerance) |
| void | setPlanningTime (double seconds) |
| double | getPlanningTime () const |
| void | constructRobotState (moveit_msgs::msg::RobotState &state) const |
| void | constructMotionPlanRequest (moveit_msgs::msg::MotionPlanRequest &request) const |
| void | constructGoal (moveit_msgs::action::MoveGroup::Goal &goal) const |
| void | setPathConstraints (const moveit_msgs::msg::Constraints &constraint) |
| bool | setPathConstraints (const std::string &constraint) |
| void | clearPathConstraints () |
| void | setTrajectoryConstraints (const moveit_msgs::msg::TrajectoryConstraints &constraint) |
| void | clearTrajectoryConstraints () |
| std::vector< std::string > | getKnownConstraints () const |
| moveit_msgs::msg::Constraints | getPathConstraints () const |
| moveit_msgs::msg::TrajectoryConstraints | getTrajectoryConstraints () const |
| void | initializeConstraintsStorage (const std::string &host, unsigned int port) |
| void | setWorkspace (double minx, double miny, double minz, double maxx, double maxy, double maxz) |
| rclcpp::Clock::SharedPtr | getClock () |
Detailed Description
Definition at line 118 of file move_group_interface.cpp.
Constructor & Destructor Documentation
◆ MoveGroupInterfaceImpl()
|
inline |
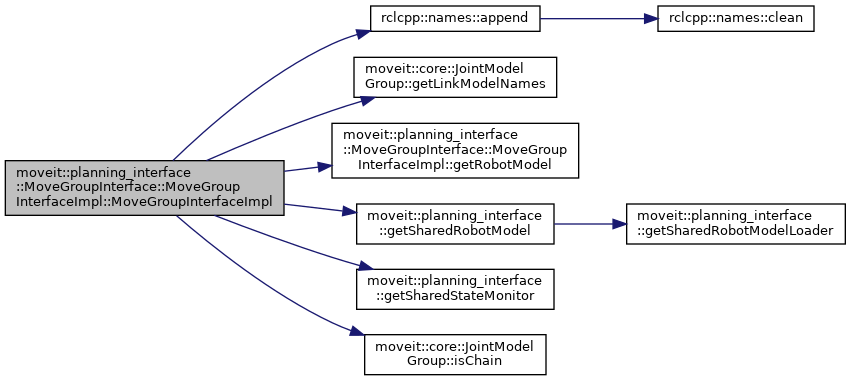
◆ ~MoveGroupInterfaceImpl()
|
inline |
Definition at line 210 of file move_group_interface.cpp.
Member Function Documentation
◆ attachObject()
|
inline |
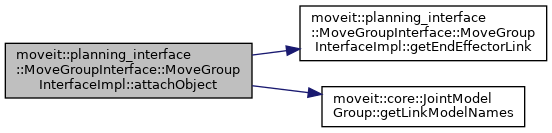
◆ clearPathConstraints()
|
inline |
Definition at line 1132 of file move_group_interface.cpp.
◆ clearPoseTarget()
|
inline |
Definition at line 513 of file move_group_interface.cpp.
◆ clearPoseTargets()
|
inline |
Definition at line 518 of file move_group_interface.cpp.
◆ clearTrajectoryConstraints()
|
inline |
Definition at line 1142 of file move_group_interface.cpp.
◆ computeCartesianPath()
|
inline |
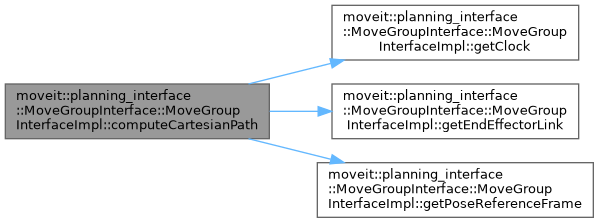
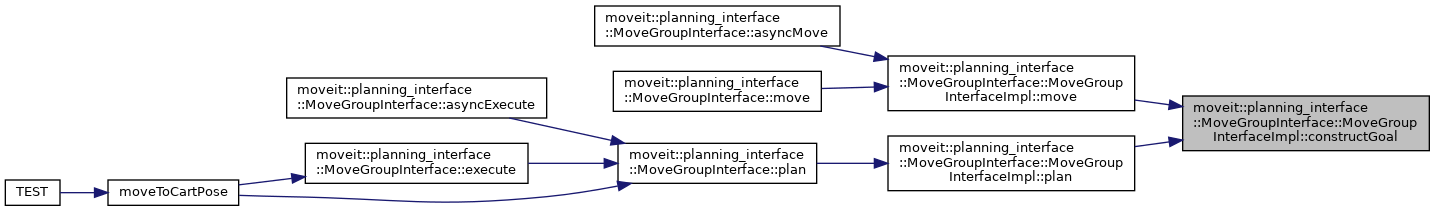
◆ constructGoal()
|
inline |
Definition at line 1100 of file move_group_interface.cpp.
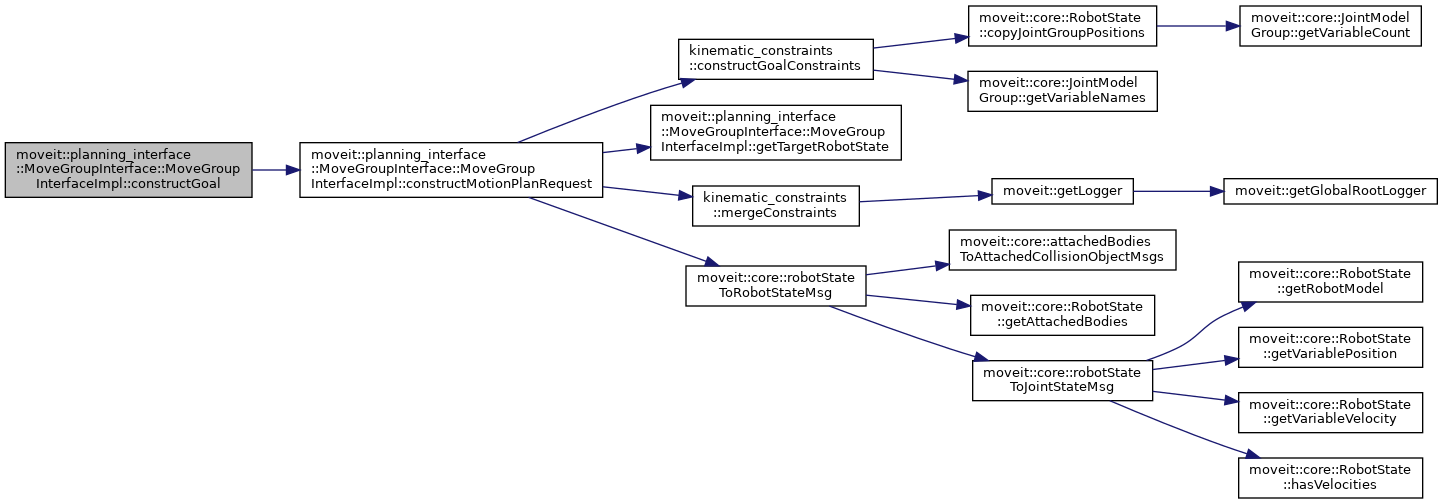
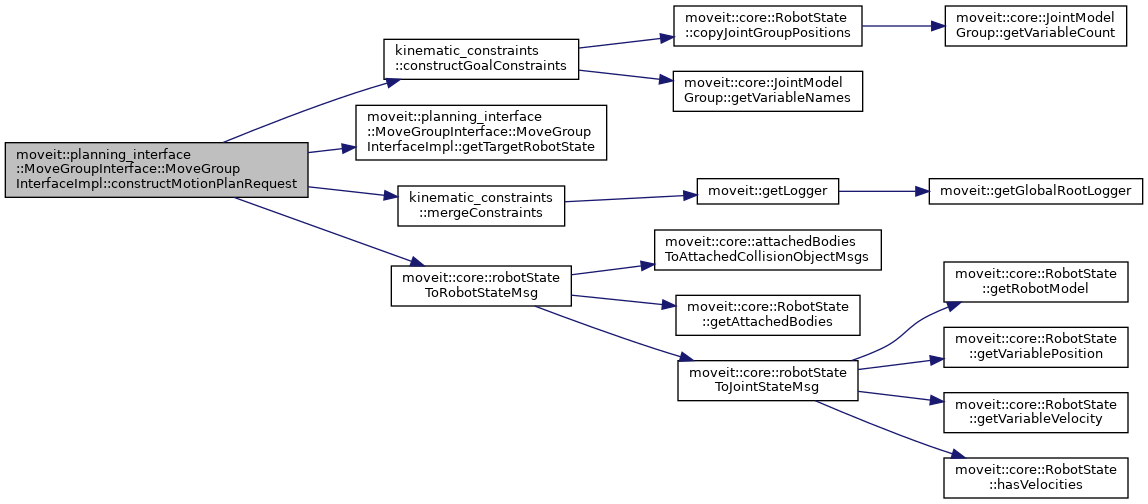
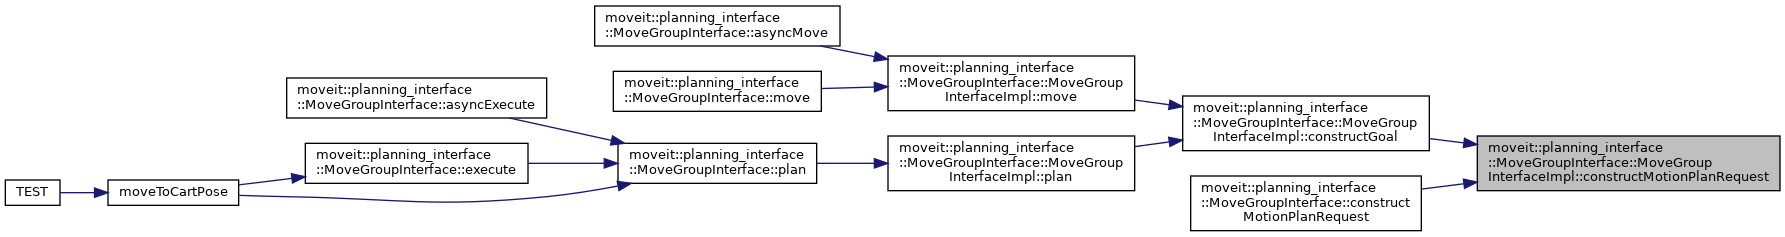
◆ constructMotionPlanRequest()
|
inline |
Definition at line 1042 of file move_group_interface.cpp.
◆ constructRobotState()
|
inline |
Definition at line 1037 of file move_group_interface.cpp.
◆ detachObject()
|
inline |
Definition at line 966 of file move_group_interface.cpp.
◆ execute()
|
inline |
Definition at line 814 of file move_group_interface.cpp.
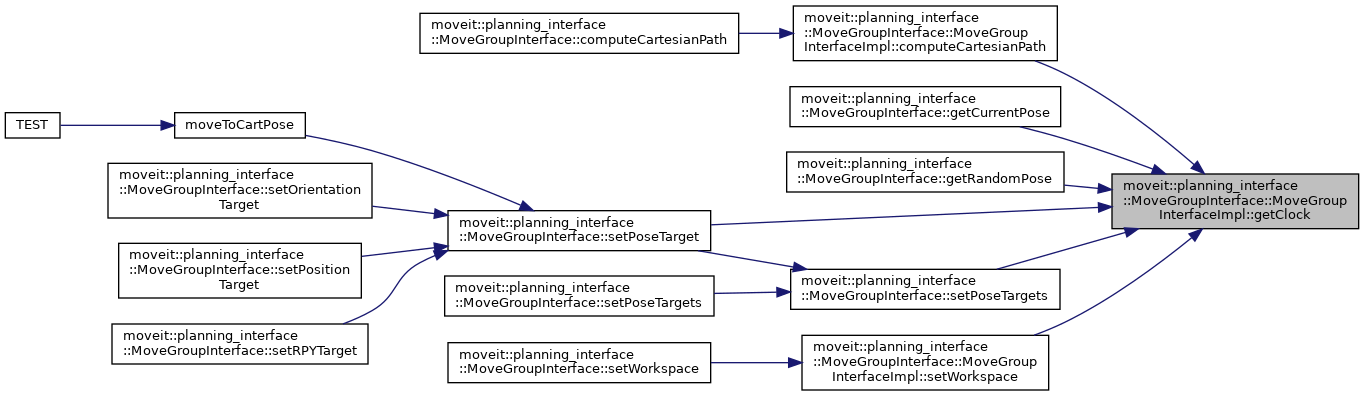
◆ getClock()
|
inline |
Definition at line 1207 of file move_group_interface.cpp.
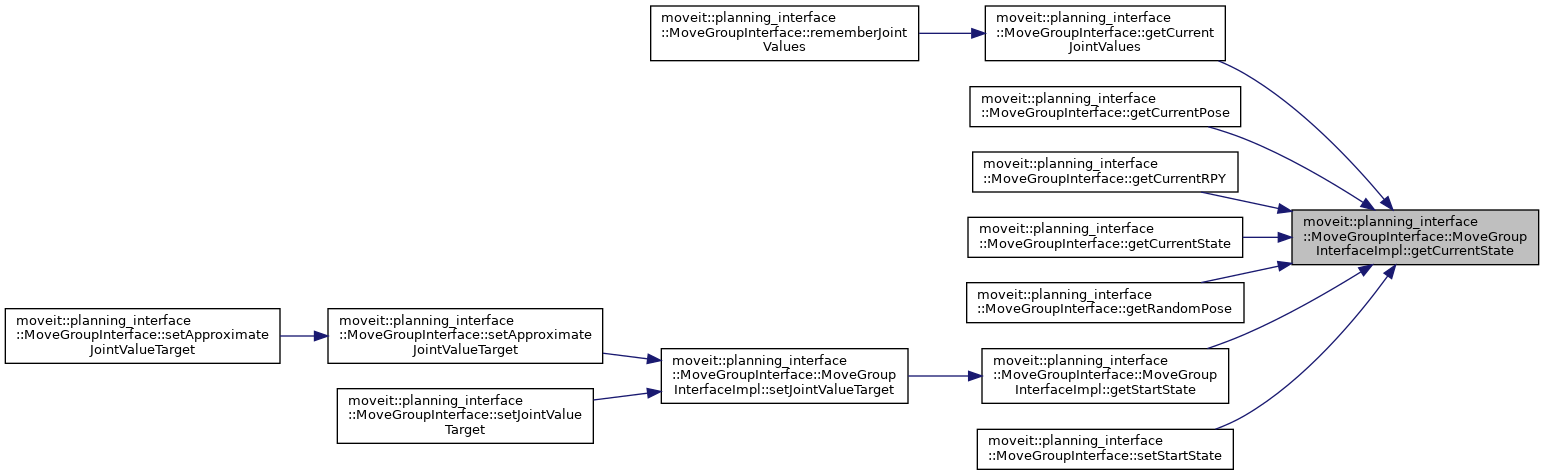
◆ getCurrentState()
|
inline |
Definition at line 640 of file move_group_interface.cpp.
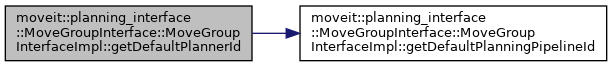
◆ getDefaultPlannerId()
|
inline |
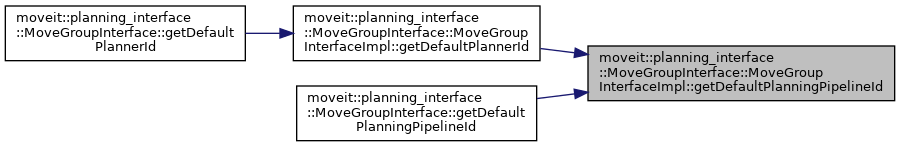
◆ getDefaultPlanningPipelineId()
|
inline |
Definition at line 312 of file move_group_interface.cpp.
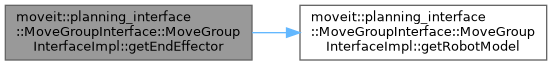
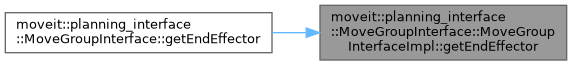
◆ getEndEffector()
|
inline |
Definition at line 528 of file move_group_interface.cpp.
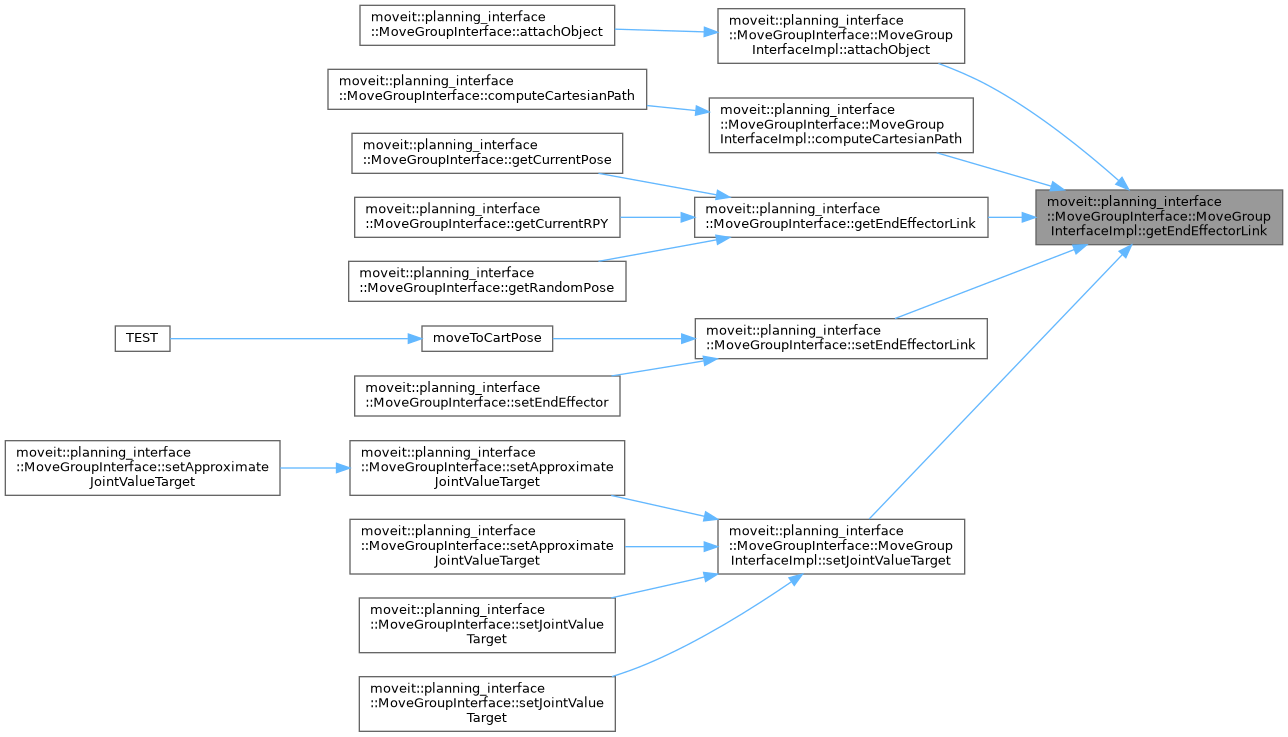
◆ getEndEffectorLink()
|
inline |
Definition at line 523 of file move_group_interface.cpp.
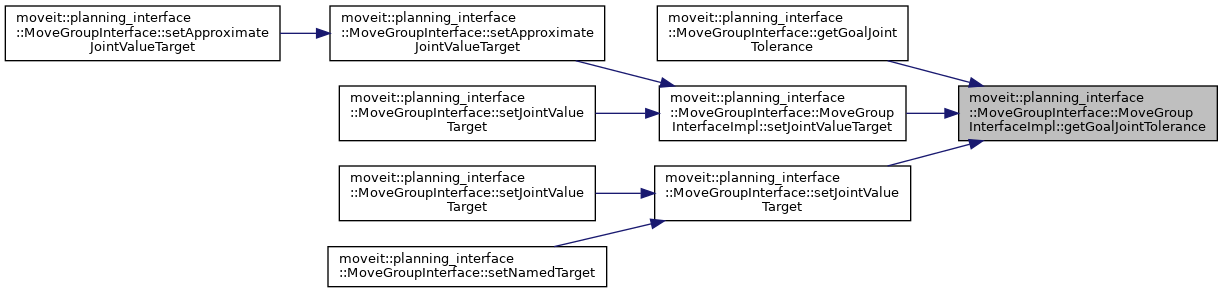
◆ getGoalJointTolerance()
|
inline |
Definition at line 1006 of file move_group_interface.cpp.
◆ getGoalOrientationTolerance()
|
inline |
Definition at line 1001 of file move_group_interface.cpp.
◆ getGoalPositionTolerance()
|
inline |
Definition at line 996 of file move_group_interface.cpp.
◆ getInterfaceDescription()
|
inline |
Definition at line 246 of file move_group_interface.cpp.
◆ getInterfaceDescriptions()
|
inline |
Definition at line 263 of file move_group_interface.cpp.
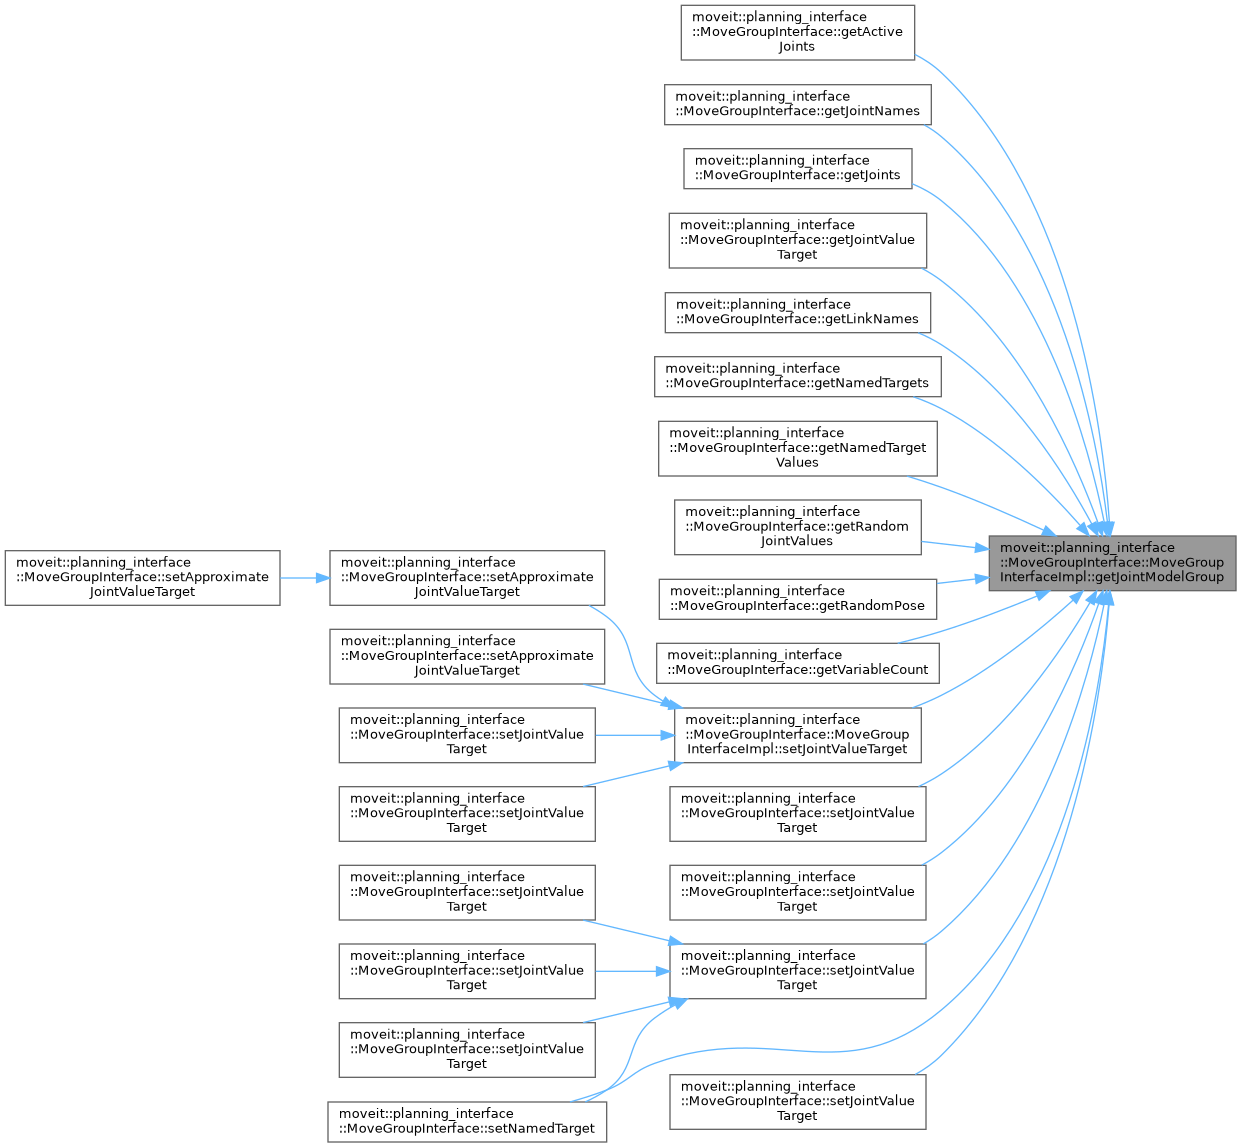
◆ getJointModelGroup()
|
inline |
Definition at line 236 of file move_group_interface.cpp.
◆ getKnownConstraints()
|
inline |
Definition at line 1147 of file move_group_interface.cpp.
◆ getMaxAccelerationScalingFactor()
|
inline |
Definition at line 385 of file move_group_interface.cpp.
◆ getMaxVelocityScalingFactor()
|
inline |
Definition at line 375 of file move_group_interface.cpp.
◆ getMoveGroupClient()
|
inline |
Definition at line 241 of file move_group_interface.cpp.
◆ getOptions()
|
inline |
Definition at line 226 of file move_group_interface.cpp.
◆ getPathConstraints()
|
inline |
Definition at line 1162 of file move_group_interface.cpp.
◆ getPlannerId()
|
inline |
Definition at line 360 of file move_group_interface.cpp.
◆ getPlannerParams()
|
inline |
Definition at line 279 of file move_group_interface.cpp.
◆ getPlanningPipelineId()
|
inline |
Definition at line 330 of file move_group_interface.cpp.
◆ getPlanningTime()
|
inline |
Definition at line 1032 of file move_group_interface.cpp.
◆ getPoseReferenceFrame()
|
inline |
Definition at line 609 of file move_group_interface.cpp.
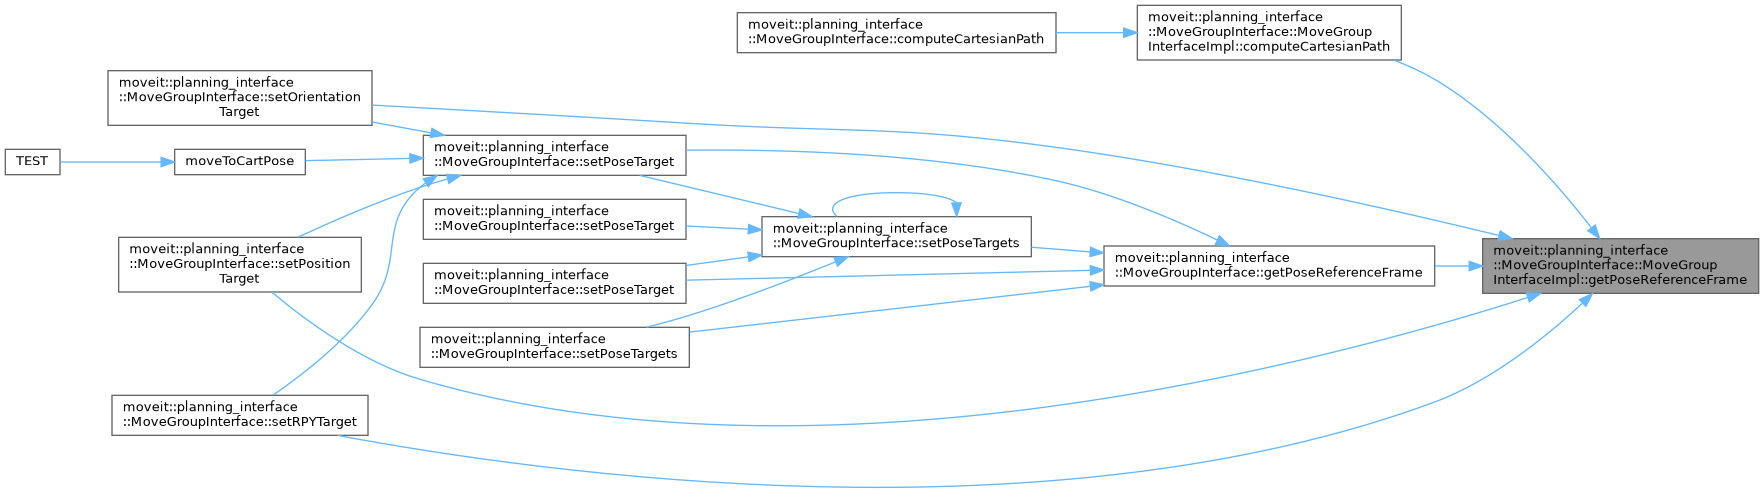
◆ getPoseTarget()
|
inline |
Definition at line 569 of file move_group_interface.cpp.
◆ getPoseTargets()
|
inline |
Definition at line 587 of file move_group_interface.cpp.
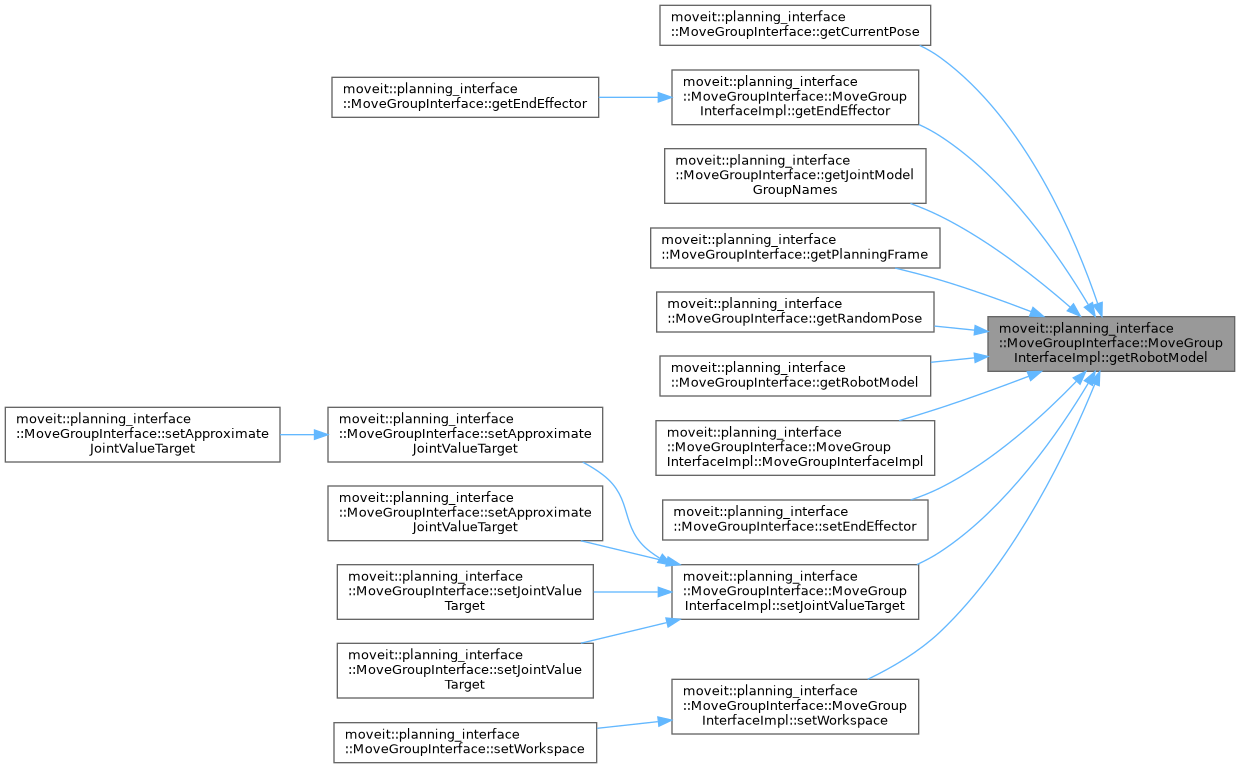
◆ getRobotModel()
|
inline |
Definition at line 231 of file move_group_interface.cpp.
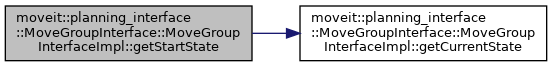
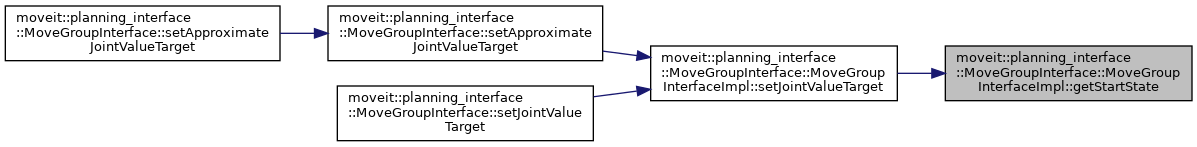
◆ getStartState()
|
inline |
Definition at line 440 of file move_group_interface.cpp.
◆ getTargetRobotState() [1/2]
|
inline |
Definition at line 412 of file move_group_interface.cpp.
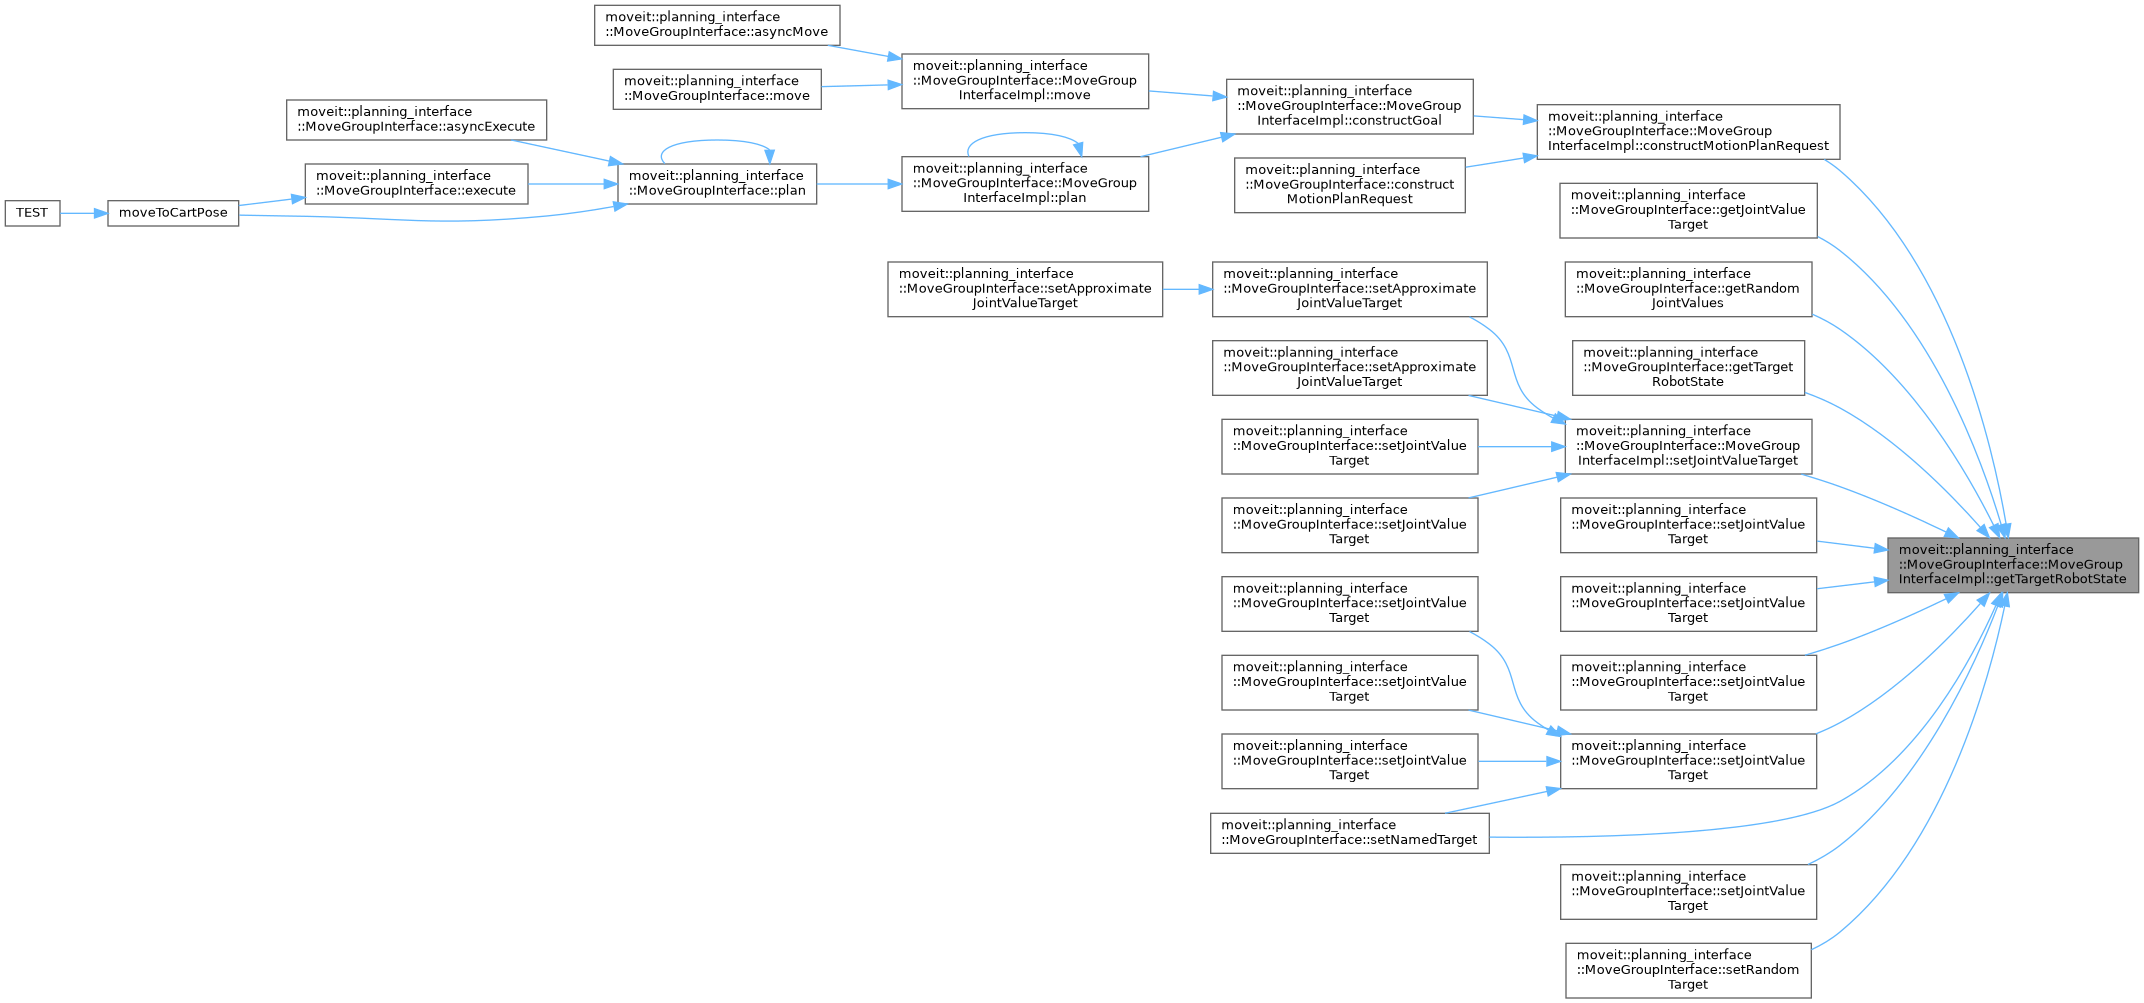
◆ getTargetRobotState() [2/2]
|
inline |
Definition at line 417 of file move_group_interface.cpp.
◆ getTargetType()
|
inline |
Definition at line 619 of file move_group_interface.cpp.
◆ getTF()
|
inline |
Definition at line 221 of file move_group_interface.cpp.
◆ getTrajectoryConstraints()
|
inline |
Definition at line 1174 of file move_group_interface.cpp.
◆ hasPoseTarget()
|
inline |
Definition at line 563 of file move_group_interface.cpp.
◆ initializeConstraintsStorage()
|
inline |
Definition at line 1186 of file move_group_interface.cpp.
◆ move()
|
inline |
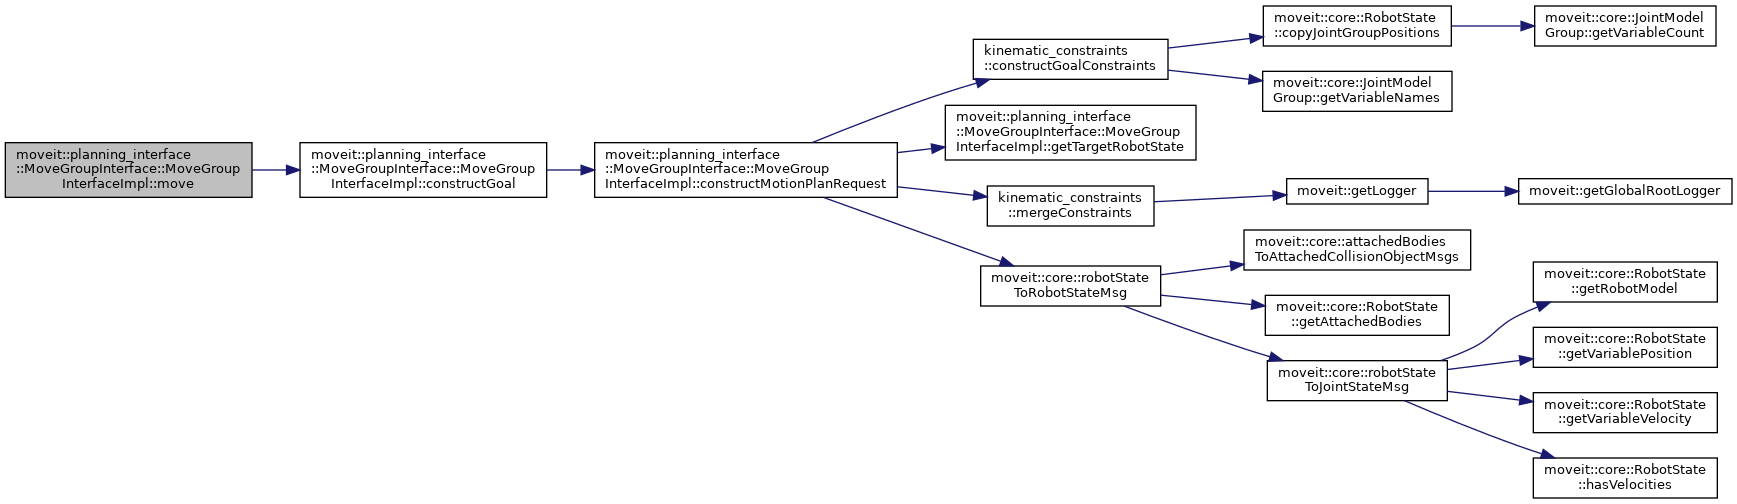
◆ plan()
|
inline |
Definition at line 662 of file move_group_interface.cpp.
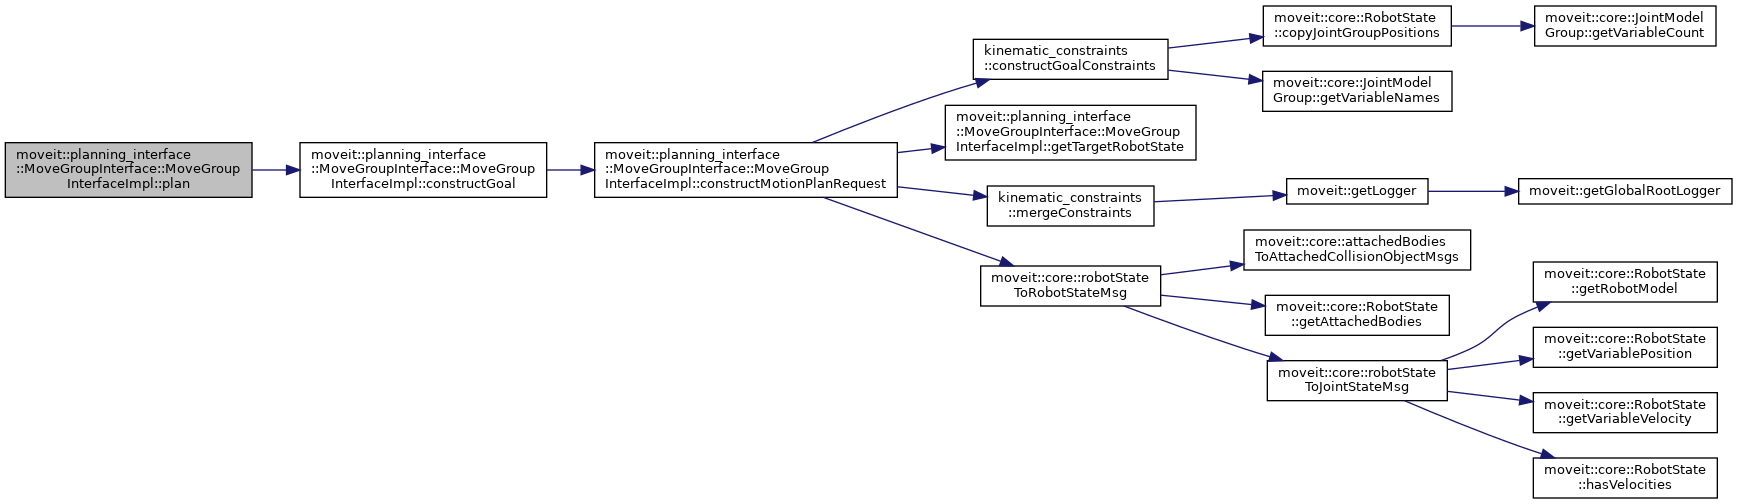
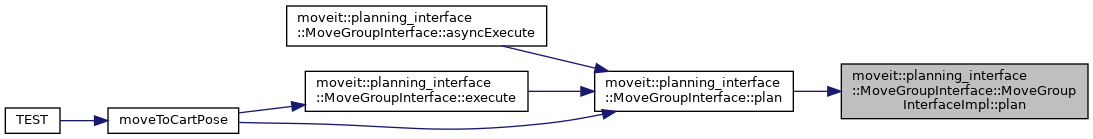
◆ setEndEffectorLink()
|
inline |
Definition at line 508 of file move_group_interface.cpp.
◆ setGoalJointTolerance()
|
inline |
Definition at line 1011 of file move_group_interface.cpp.
◆ setGoalOrientationTolerance()
|
inline |
Definition at line 1021 of file move_group_interface.cpp.
◆ setGoalPositionTolerance()
|
inline |
Definition at line 1016 of file move_group_interface.cpp.
◆ setJointValueTarget()
|
inline |
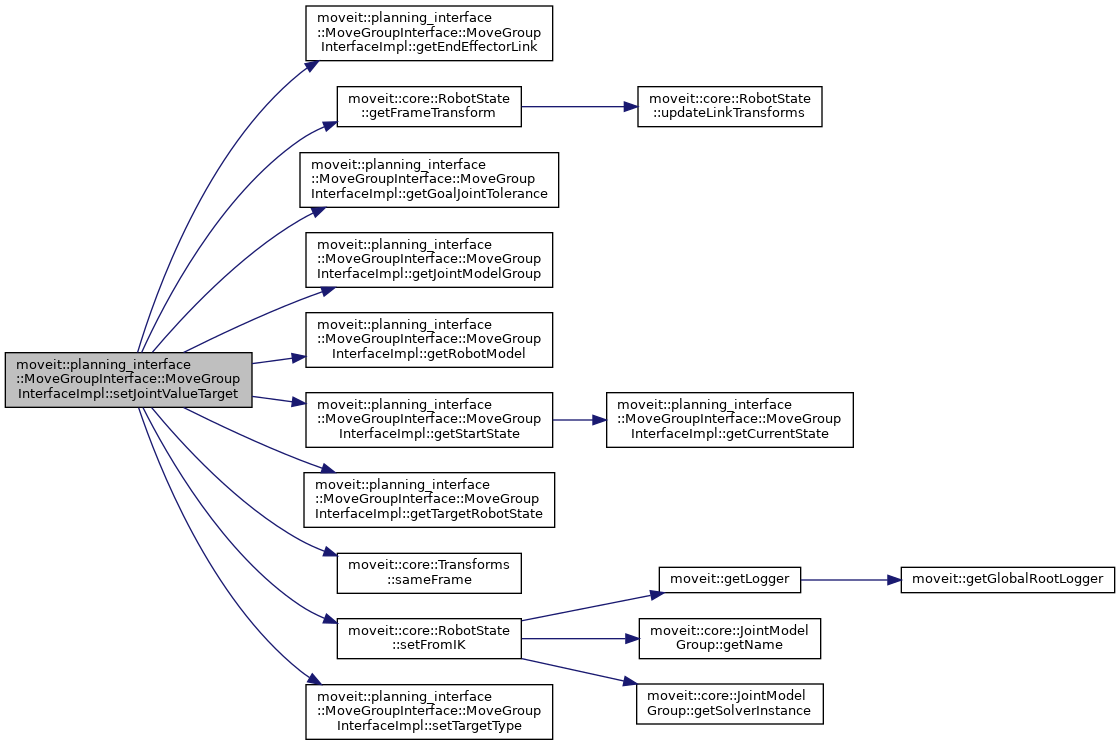
◆ setMaxAccelerationScalingFactor()
|
inline |
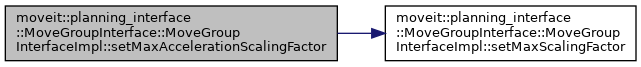
◆ setMaxScalingFactor()
|
inline |
Definition at line 390 of file move_group_interface.cpp.
◆ setMaxVelocityScalingFactor()
|
inline |
◆ setNumPlanningAttempts()
|
inline |
Definition at line 365 of file move_group_interface.cpp.
◆ setPathConstraints() [1/2]
|
inline |
Definition at line 1105 of file move_group_interface.cpp.
◆ setPathConstraints() [2/2]
|
inline |
Definition at line 1110 of file move_group_interface.cpp.
◆ setPlannerId()
|
inline |
Definition at line 355 of file move_group_interface.cpp.
◆ setPlannerParams()
|
inline |
Definition at line 297 of file move_group_interface.cpp.
◆ setPlanningPipelineId()
|
inline |
Definition at line 319 of file move_group_interface.cpp.
◆ setPlanningTime()
|
inline |
Definition at line 1026 of file move_group_interface.cpp.
◆ setPoseReferenceFrame()
|
inline |
Definition at line 604 of file move_group_interface.cpp.
◆ setPoseTargets()
|
inline |
Definition at line 544 of file move_group_interface.cpp.
◆ setStartState() [1/2]
|
inline |
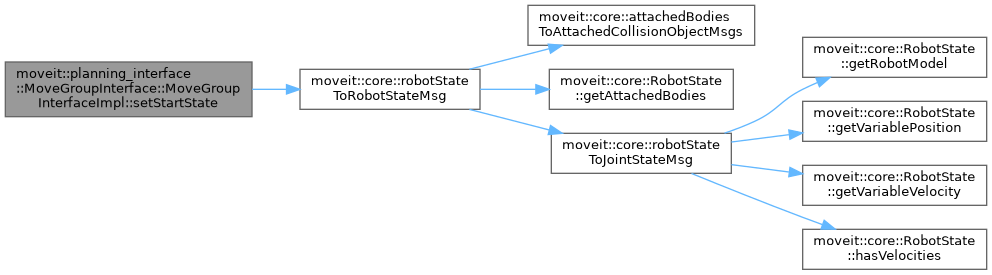
◆ setStartState() [2/2]
|
inline |
Definition at line 422 of file move_group_interface.cpp.
◆ setStartStateToCurrentState()
|
inline |
Definition at line 433 of file move_group_interface.cpp.

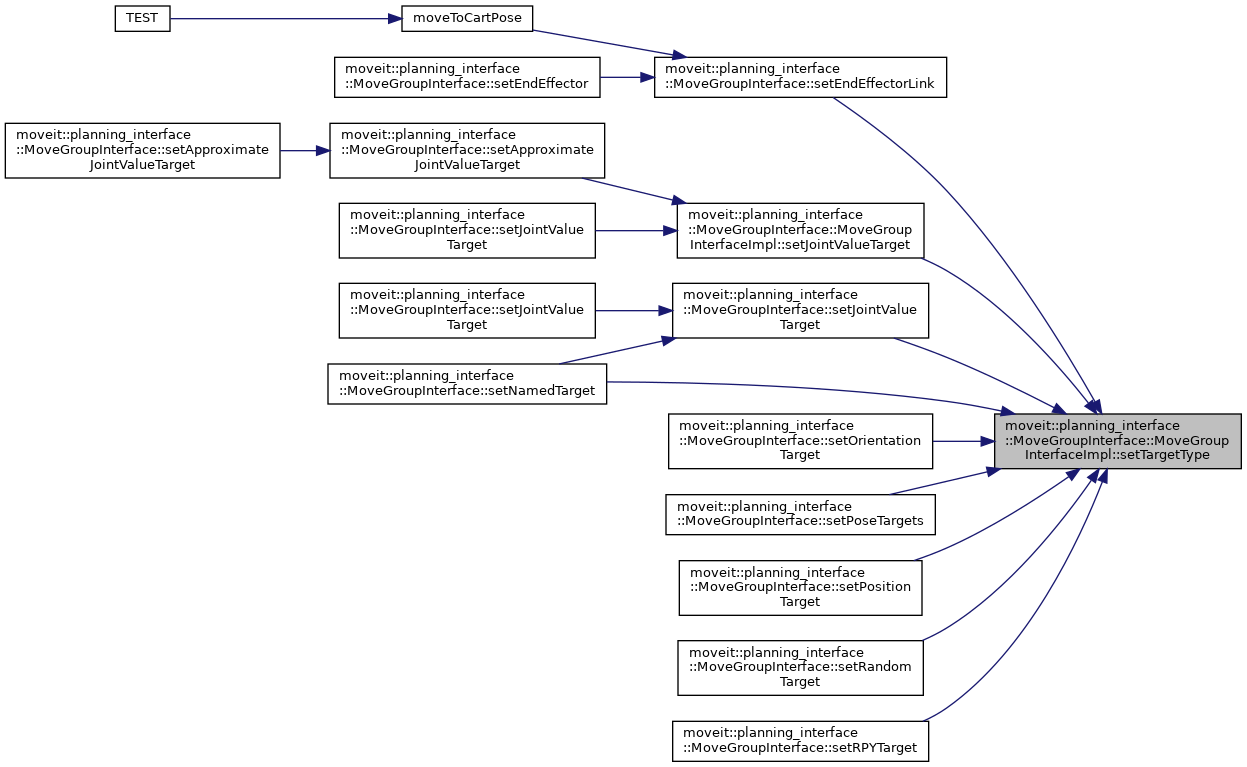
◆ setTargetType()
|
inline |
Definition at line 614 of file move_group_interface.cpp.
◆ setTrajectoryConstraints()
|
inline |
Definition at line 1137 of file move_group_interface.cpp.
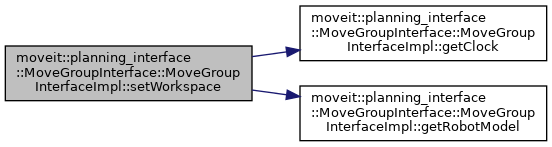
◆ setWorkspace()
|
inline |
◆ startStateMonitor()
|
inline |
Definition at line 624 of file move_group_interface.cpp.
◆ stop()
|
inline |
Definition at line 926 of file move_group_interface.cpp.
The documentation for this class was generated from the following file:
- moveit_ros/planning_interface/move_group_interface/src/move_group_interface.cpp
Generated by
 1.15.0